

5.8.5.4 Consistency Equation Solution
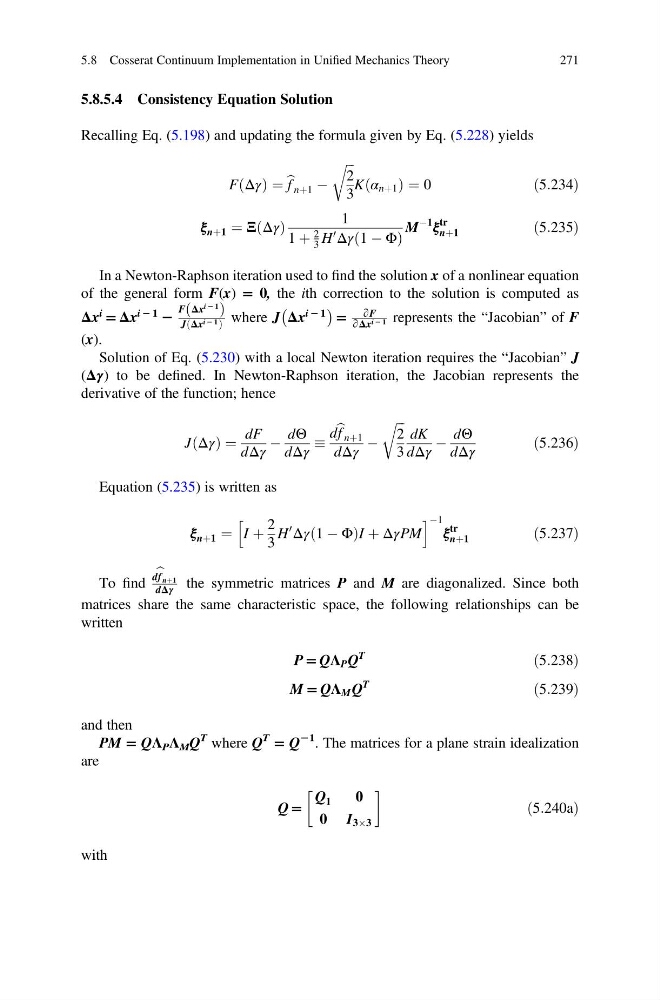
Recalling Eq. (5.198) and updating the formula given by Eq. (5.228) yields
F Δγ
ð Þ ¼ b f nþ1 À
ffiffi ffi
2
3
r
K α nþ1
ð
Þ¼0
ð5:234Þ
ξ nþ1 ¼ Ξ Δγ
ð Þ
1
1 þ
2
3 H
0
Δγ 1 À Φ
ð
Þ
M
À1
ξ
tr
nþ1
ð5:235Þ
In a Newton-Raphson iteration used to find the solution x of a nonlinear equation
of the general form F(x) = 0, the ith correction to the solution is computed as
Δx
i
= Δx
i 2 1
2
F Δx
i 2 1
ð
Þ
J Δx i 2 1
ð
Þ
where J Δx
i 2 1
À
Á =
∂F
∂Δx i 2 1 represents the “Jacobian” of F
(x).
Solution of Eq. (5.230) with a local Newton iteration requires the “Jacobian” J
(Δγ) to be defined. In Newton-Raphson iteration, the Jacobian represents the
derivative of the function; hence
J Δγ
ð Þ ¼
dF
dΔγ
À
dΘ
dΔγ
d b f nþ1
dΔγ
À
ffiffi ffi
2
3
r
dK
dΔγ
À
dΘ
dΔγ
ð5:236Þ
Equation (5.235) is written as
ξ nþ1 ¼ I þ
2
3
H
0
Δγ 1 À Φ
ð
ÞI þ ΔγPM
h
i À1
ξ
tr
nþ1
ð5:237Þ
To find
d b f nþ1
dΔγ the symmetric matrices P and M are diagonalized. Since both
matrices share the same characteristic space, the following relationships can be
written
P = QΛ P Q
T
ð5:238Þ
M = QΛ M Q
T
ð5:239Þ
and then
PM = QΛ P Λ M Q
T where Q
T
= Q
21 . The matrices for a plane strain idealization
are
Q =
Q 1
0
0 I 3Â3
!
ð5:240aÞ
with
5.8 Cosserat Continuum Implementation in Unified Mechanics Theory
271