

4 Contact Hamiltonian Systems for Probability Distribution Functions …
69
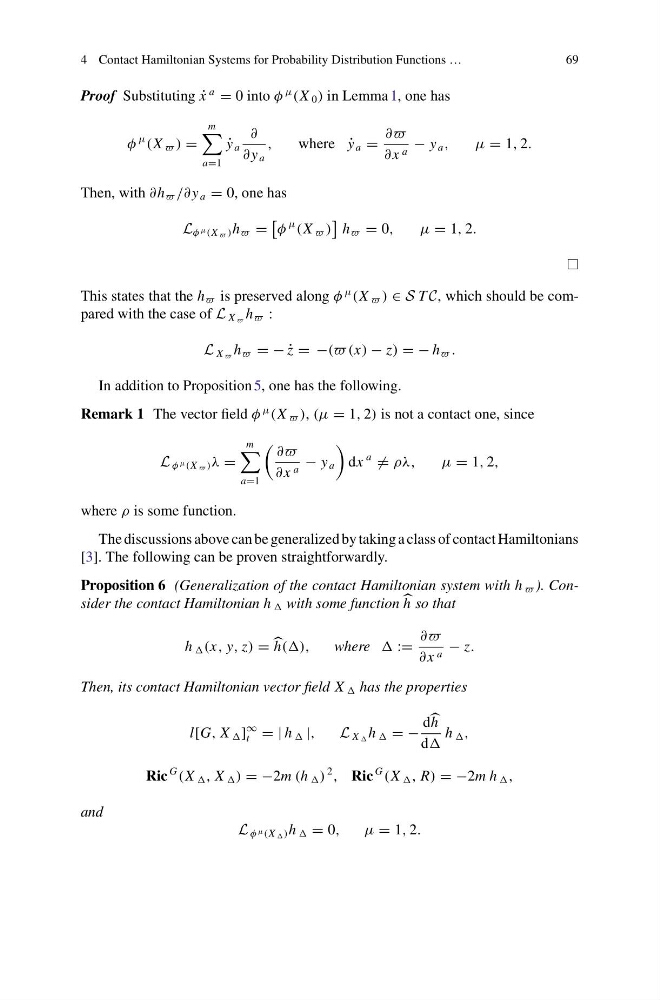
Proof Substituting ˙
x
a
= 0 into φ
μ
(X 0 ) in Lemma 1, one has
φ
μ
(X ) =
m
a=1
˙
y a
∂
∂ y a
,
where ˙
y a =
∂∂
∂ x a − y a ,
μ = 1, 2.
Then, with ∂h /∂ y a = 0, one has
L φ μ (X ) h =
φ
μ
(X )
h = 0,
μ = 1, 2.
This states that the h is preserved along φ
μ
(X ) ∈ S T C, which should be compared with the case of L X h :
L X h = − ˙
z = −(( (x) − z) = − h .
In addition to Proposition 5, one has the following.
Remark 1 The vector field φ
μ
(X ), (μ = 1, 2) is not a contact one, since
L φ μ (X ) λ =
m
a=1
∂∂
∂ x a − y a
dx
a
= ρλ,
μ = 1, 2,
where ρ is some function.
The discussions above can be generalized by taking a class of contact Hamiltonians
[3]. The following can be proven straightforwardly.
Proposition 6 (Generalization of the contact Hamiltonian system with h ). Consider the contact Hamiltonian h with some function h so that
h (x, y, z) = h((),
where :=
∂∂
∂ x a − z.
Then, its contact Hamiltonian vector field X has the properties
l[G, X ]
∞
t = | h |,
L X h = −
d h
d
h ,
Ric
G
(X , X ) = −2m (h )
2
, Ric
G
(X , R) = −2m h ,
and
L φ μ (X ) h = 0,
μ = 1, 2.