

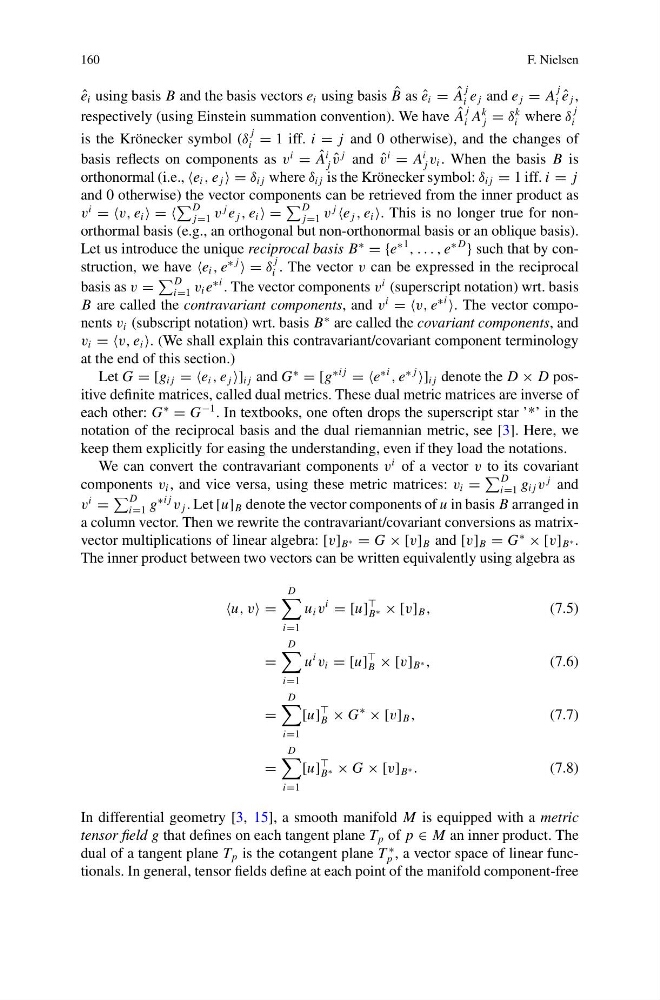
160
F. Nielsen
ˆ
e i using basis B and the basis vectors e i using basis ˆ
B as ˆ
e i = ˆ
A
j
i e j and e j = A
j
i ˆ
e j ,
respectively (using Einstein summation convention). We have ˆ
A
j
i A
k
j = δ
k
i where δ
j
i
is the Krönecker symbol (δ
j
i = 1 iff. i = j and 0 otherwise), and the changes of
basis reflects on components as v
i
= ˆ
A
i
j ˆ
v
j and ˆ
v
i
= A
i
j v i . When the basis B is
orthonormal (i.e., e i , e j = δ i j where δ i j is the Krönecker symbol: δ i j = 1 iff. i = j
and 0 otherwise) the vector components can be retrieved from the inner product as
v
i
= =v, e i = =
D
j=1 v
j e j , e i =
D
j=1 v
j
e j , e i . This is no longer true for nonorthormal basis (e.g., an orthogonal but non-orthonormal basis or an oblique basis).
Let us introduce the unique reciprocal basis B
∗
= {e
∗1
, . . . , e
∗ D
} such that by construction, we have e i , e
∗ j
= δ
j
i . The vector v can be expressed in the reciprocal
basis as v =
D
i=1 v i e
∗i . The vector components v
i (superscript notation) wrt. basis
B are called the contravariant components, and v
i
= =v, e
∗i
. The vector components v i (subscript notation) wrt. basis B
∗ are called the covariant components, and
v i = =v, e i . (We shall explain this contravariant/covariant component terminology
at the end of this section.)
Let G = [g i j = =e i , e j ] i j and G
∗
= [g
∗i j
= =e
∗i
, e
∗ j
] i j denote the D × D positive definite matrices, called dual metrics. These dual metric matrices are inverse of
each other: G
∗
= G
−1 . In textbooks, one often drops the superscript star ’*’ in the
notation of the reciprocal basis and the dual riemannian metric, see [3]. Here, we
keep them explicitly for easing the understanding, even if they load the notations.
We can convert the contravariant components v
i of a vector v to its covariant
components v i , and vice versa, using these metric matrices: v i =
D
i=1 g i j v
j and
v
i
=
D
i=1 g
∗i j
v j . Let [u] B denote the vector components of u in basis B arranged in
a column vector. Then we rewrite the contravariant/covariant conversions as matrixvector multiplications of linear algebra: [v] B ∗ = G × [v] B and [v] B = G
∗
× [v] B ∗ .
The inner product between two vectors can be written equivalently using algebra as
u, v =
D
i=1
u i v
i
= [u]
B ∗ × [v] B ,
(7.5)
=
D
i=1
u
i
v i = [u]
B × [v] B ∗ ,
(7.6)
=
D
i=1
[u]
B × G
∗
× [v] B ,
(7.7)
=
D
i=1
[u]
B ∗ × G × [v] B ∗ .
(7.8)
In differential geometry [3, 15], a smooth manifold M is equipped with a metric
tensor field g that defines on each tangent plane T p of p ∈ M an inner product. The
dual of a tangent plane T p is the cotangent plane T
∗
p , a vector space of linear functionals. In general, tensor fields define at each point of the manifold component-free