

–50
0
50
100
150
Torque (Nm)
τ 1 Real torque of joint 1
τ 2 Real resulting torque of joint 2
Downswing
Backswing
Follow-through
t t = 0.50
t m = 0.74
t f = 1.16
0
0.2
0.4
0.6
0.8
1
1.2
Time (s)
(c)
–15
–10
–5
0
5
10
15
20
25
30
35
Torque (Nm)
τ 2p Real passive torque of joint 2
Downswing
Backswing
Follow-through
t t = 0.50
t m = 0.74
t f = 1.16
0
0.2
0.4
0.6
0.8
1
1.2
Time (s)
(d)
81
Human-Inspired Hyper Dynamic Manipulation
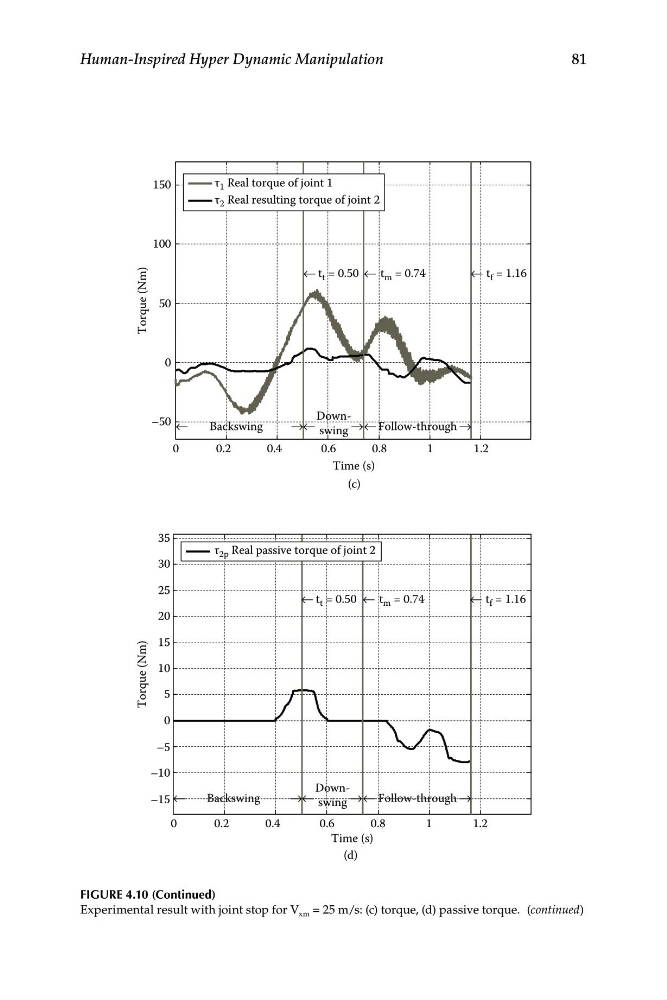
FIGURE 4.10 (Continued)
Experimental result with joint stop for V xm = 25 m/s: (c) torque, (d) passive torque. (continued)
0
50
100
150
Torque (Nm)
τ 1 Real torque of joint 1
τ 2 Real resulting torque of joint 2
Downswing
Backswing
Follow-through
t t = 0.50
t m = 0.74
t f = 1.16
0
0.2
0.4
0.6
0.8
1
1.2
Time (s)
(c)
–15
–10
–5
0
5
10
15
20
25
30
35
Torque (Nm)
τ 2p Real passive torque of joint 2
Downswing
Backswing
Follow-through
t t = 0.50
t m = 0.74
t f = 1.16
0
0.2
0.4
0.6
0.8
1
1.2
Time (s)
(d)
81
Human-Inspired Hyper Dynamic Manipulation
FIGURE 4.10 (Continued)
Experimental result with joint stop for V xm = 25 m/s: (c) torque, (d) passive torque. (continued)