

64
Biologically Inspired Robotics
Therefore, it is possible to realize efficient dynamic manipulations by utilizing the joint stop, compared to conventional manipulators limited by the
load capability of actuators.
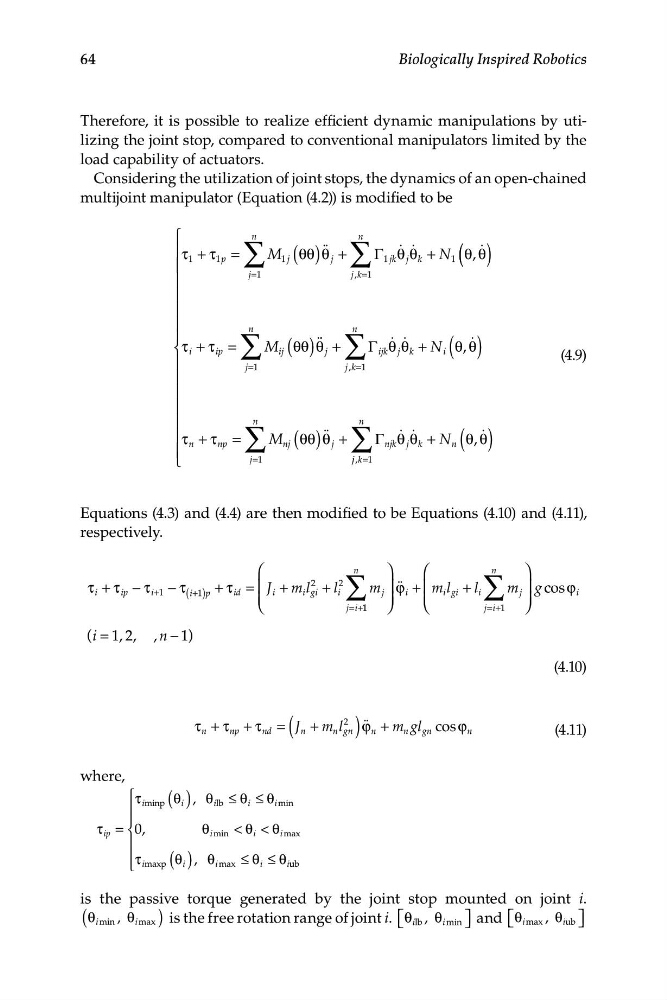
Considering the utilization of joint stops, the dynamics of an open-chained
multijoint manipulator (Equation (4.2)) is modified to be
⎧
⎪ τ +
= ∑
n
( )
n
τ
θθ θ qq
1
1p
M 1 j
Γ
N
⎪
j + ∑
q q
1 jk θ j θ k + 1 ( ( θ, θ q )
⎪
=
=
j 1
j k
, 1
⎪
��������������������
⎪
⎪
⎪
n
n
⎨ τ i + τ =
q
ip
∑ i ( )
θθ θ q q
M
j +
j
Γ θ q q
N ( q
ijk j θ k + i θ, θ )
(4.9)
⎪
j=1
∑
j k
, =1
⎪
⎪�������
� �������������
⎪
⎪
τ + τ np = ∑
n
n
⎪
M
qq
q q
q
n
⎪
n
j ( )
θθ θ j + ∑ Γ njk θ j θ k + N n ( θ θ
, )
⎩
j=1
j k
j , =1
Equations (4.3) and (4.4) are then modified to be Equations (4.10) and (4.11),
respectively.
⎛
n
⎞
⎛
n
⎞
τ
2
2
i + τ p − τ
i
i+1 − τ (i+1 ) p + τ id = ⎜ J i + m i l gi + l i ∑ m j ⎟ ϕ qq i + ⎜ m l
i gi + l i ∑ m j ⎟ g c cos ϕ
⎜
i
⎝
j i
⎟
= +1 1
⎜
⎠
⎝
j i
= +1
⎟ ⎠
(i = 1 2
, , �, n − 1)
(4.10)
τ
2
n + τ np + τ nd = ( J n + m n l gn ) ϕ qq + m gl gn cos ϕ n
(4.11)
n
n
where,
⎧ τ iminp ( )
θ i , θ ilb ≤ θ
⎪
i ≤ θ i min
⎪
τ ip = ⎨ 0,
θ i min < θ i < θ i max
⎪
⎪τ
θ
( )
i
⎩ imaxp θ , θ i max ≤ i ≤ θ iub u
is the passive torque generated by the joint stop mounted on joint i.
(θL min , θ L max ) is the free rotation range of joint i. ⎣ ⎡θ Llb , θ L min ⎦ ⎤ and ⎣ ⎡θ L max , θ Lub ⎤ ⎦
Biologically Inspired Robotics
Therefore, it is possible to realize efficient dynamic manipulations by utilizing the joint stop, compared to conventional manipulators limited by the
load capability of actuators.
Considering the utilization of joint stops, the dynamics of an open-chained
multijoint manipulator (Equation (4.2)) is modified to be
⎧
⎪ τ +
= ∑
n
( )
n
τ
θθ θ qq
1
1p
M 1 j
Γ
N
⎪
j + ∑
q q
1 jk θ j θ k + 1 ( ( θ, θ q )
⎪
=
=
j 1
j k
, 1
⎪
��������������������
⎪
⎪
⎪
n
n
⎨ τ i + τ =
q
ip
∑ i ( )
θθ θ q q
M
j +
j
Γ θ q q
N ( q
ijk j θ k + i θ, θ )
(4.9)
⎪
j=1
∑
j k
, =1
⎪
⎪�������
� �������������
⎪
⎪
τ + τ np = ∑
n
n
⎪
M
q q
q
n
⎪
n
j ( )
θθ θ j + ∑ Γ njk θ j θ k + N n ( θ θ
, )
⎩
j=1
j k
j , =1
Equations (4.3) and (4.4) are then modified to be Equations (4.10) and (4.11),
respectively.
⎛
n
⎞
⎛
n
⎞
τ
2
2
i + τ p − τ
i
i+1 − τ (i+1 ) p + τ id = ⎜ J i + m i l gi + l i ∑ m j ⎟ ϕ qq i + ⎜ m l
i gi + l i ∑ m j ⎟ g c cos ϕ
⎜
i
⎝
j i
⎟
= +1 1
⎜
⎠
⎝
j i
= +1
⎟ ⎠
(i = 1 2
, , �, n − 1)
(4.10)
τ
2
n + τ np + τ nd = ( J n + m n l gn ) ϕ qq + m gl gn cos ϕ n
(4.11)
n
n
where,
⎧ τ iminp ( )
θ i , θ ilb ≤ θ
⎪
i ≤ θ i min
⎪
τ ip = ⎨ 0,
θ i min < θ i < θ i max
⎪
⎪τ
θ
( )
i
⎩ imaxp θ , θ i max ≤ i ≤ θ iub u
is the passive torque generated by the joint stop mounted on joint i.
(θL min , θ L max ) is the free rotation range of joint i. ⎣ ⎡θ Llb , θ L min ⎦ ⎤ and ⎣ ⎡θ L max , θ Lub ⎤ ⎦