

160
T. Krak
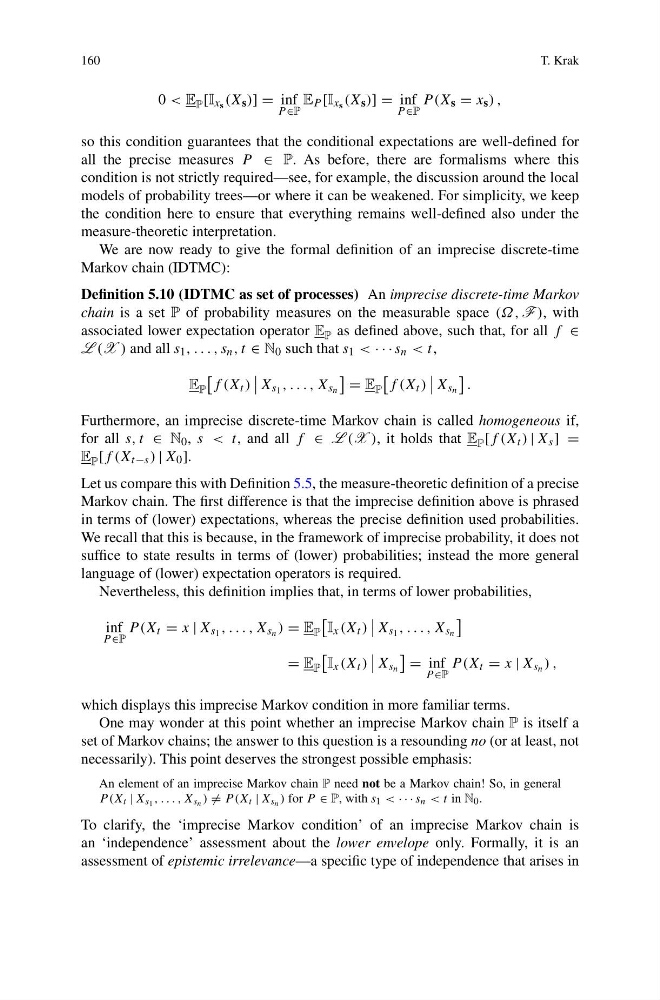
0 < E P [I x s (X s )] = inf
P ∈P
E P [I x s (X s )] = inf
P ∈P
P (X s = x s ) ,
so this condition guarantees that the conditional expectations are well-defined for
all the precise measures P ∈ P. As before, there are formalisms where this
condition is not strictly required—see, for example, the discussion around the local
models of probability trees—or where it can be weakened. For simplicity, we keep
the condition here to ensure that everything remains well-defined also under the
measure-theoretic interpretation.
We are now ready to give the formal definition of an imprecise discrete-time
Markov chain (IDTMC):
Definition 5.10 (IDTMC as set of processes) An imprecise discrete-time Markov
chain is a set P of probability measures on the measurable space (Ω, F ), with
associated lower expectation operator E P as defined above, such that, for all f ∈
L (X ) and all s 1 , . . . , s n , t ∈ N 0 such that s 1 < · · · s n < t,
E P
f (X t )
X s 1 , . . . , X s n
= E P
f (X t )
X s n
.
Furthermore, an imprecise discrete-time Markov chain is called homogeneous if,
for all s, t ∈ N 0 , s < t, and all f ∈ L (X ), it holds that E P [f (X t ) | X s ] =
E P [f (X t−s ) | X 0 ].
Let us compare this with Definition 5.5, the measure-theoretic definition of a precise
Markov chain. The first difference is that the imprecise definition above is phrased
in terms of (lower) expectations, whereas the precise definition used probabilities.
We recall that this is because, in the framework of imprecise probability, it does not
suffice to state results in terms of (lower) probabilities; instead the more general
language of (lower) expectation operators is required.
Nevertheless, this definition implies that, in terms of lower probabilities,
inf
P ∈P
P (X t = x | X s 1 , . . . , X s n ) = E P
I x (X t )
X s 1 , . . . , X s n
= E P
I x (X t )
X s n
= inf
P ∈P
P (X t = x | X s n ) ,
which displays this imprecise Markov condition in more familiar terms.
One may wonder at this point whether an imprecise Markov chain P is itself a
set of Markov chains; the answer to this question is a resounding no (or at least, not
necessarily). This point deserves the strongest possible emphasis:
An element of an imprecise Markov chain P need not be a Markov chain! So, in general
P (X t | X s 1 , . . . , X sn ) = P (X t | X sn ) for P ∈ P, with s 1 < · · · s n < t in N 0 .
To clarify, the ‘imprecise Markov condition’ of an imprecise Markov chain is
an ‘independence’ assessment about the lower envelope only. Formally, it is an
assessment of epistemic irrelevance—a specific type of independence that arises in