

E1C07 09/14/2010
14:43:50 Page 284
have I/O ports to interface with other devices to measure and to output instructions. Programming
allows for such operations as which sensors to measure and when and how often, and data
reduction. Programming can allow for decision-making and feedback to control process
variables. A cost-effective microprocessor system may be derived from a programmable logic
controller (PLC).
Computer-based data-acquisition systems are hybrid systems combining a data-acquisition
package with both the microprocessor and human interface capability of a personal computer (PC).
The interface between external instruments and the PC is done either through the use of an I/O
board, an external serial or parallel communication port, an external serial bus, or a wireless port.
They all provide direct access to memory storage and connection to the Internet, an increasingly
useful method to transmit data between locations.
7.7 DATA-ACQUISITION SYSTEM COMPONENTS
Signal Conditioning: Filters and Amplification
Analog signals usually require some type of signal conditioning to properly interface with a digital
system. Filters and amplifiers are the most common components used.
Filters
Analog filters are used to control the frequency content of the signal being sampled. Anti-alias
analog filters remove signal information above the Nyquist frequency prior to sampling. Not all
data-acquisition boards contain analog filters, so these necessary components are often overlooked
and may need to be added.
Digital filters are effective for signal analysis. They cannot be used to prevent aliasing. One
digital filtering scheme involves taking the Fourier transform of the sampled signal, multiplying the
signal amplitude in the targeted frequency domain to attain the desired frequency response (i.e., type
of filter and desired filter settings), and transforming the signal back into time domain using the
inverse Fourier transform (1,2).
A simpler digital filter is the moving average or smoothing filter, which is used for removing
noise or showing trends. Essentially, this filter replaces a current data point value with an average
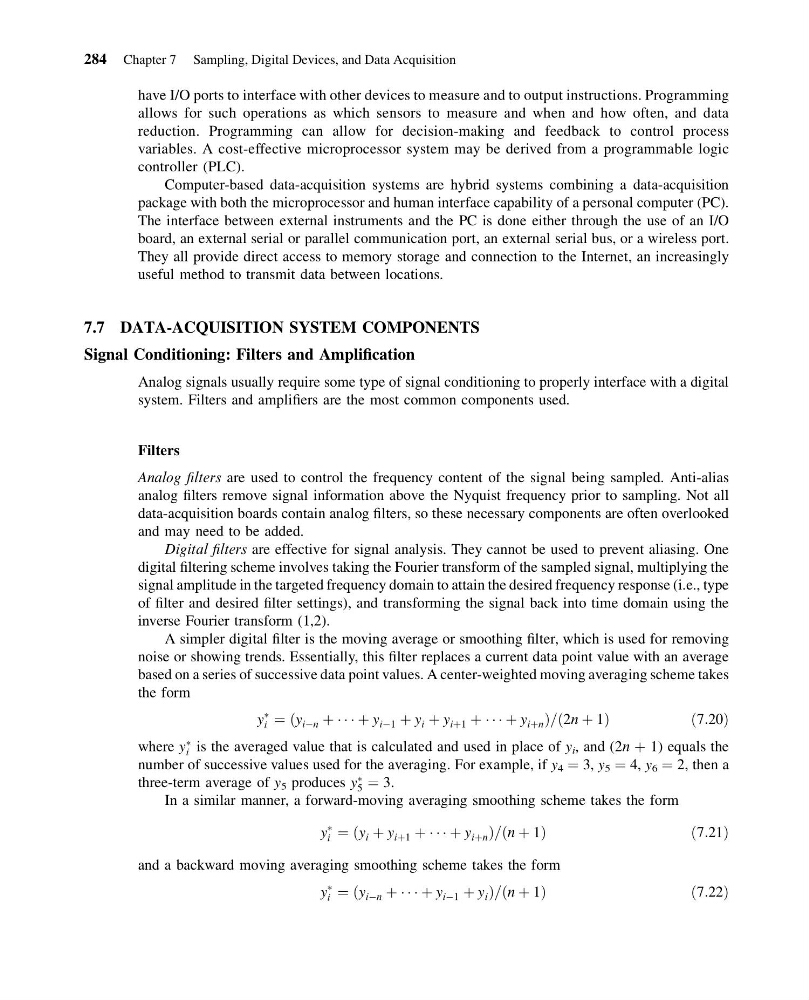
based on a series of successive data point values. A center-weighted moving averaging scheme takes
the form
y
Ã
i ¼ ðy iÀn þ Á Á Á þ y iÀ1 þ y i þ y iþ1 þ Á Á Á þ y iþn Þ=ð2n þ 1Þ
ð 7:20Þ
where y
Ã
i is the averaged value that is calculated and used in place of y i , and (2n þ 1) equals the
number of successive values used for the averaging. For example, if y 4 ¼ 3, y 5 ¼ 4, y 6 ¼ 2, then a
three-term average of y 5 produces y
Ã
5 ¼ 3.
In a similar manner, a forward-moving averaging smoothing scheme takes the form
y
Ã
i ¼ ðy i þ y iþ1 þ Á Á Á þ y iþn Þ=ðn þ 1Þ
ð 7:21Þ
and a backward moving averaging smoothing scheme takes the form
y
Ã
i ¼ ðy iÀn þ Á Á Á þ y iÀ1 þ y i Þ=ðn þ 1Þ
ð 7:22Þ
284 Chapter 7 Sampling, Digital Devices, and Data Acquisition