

E1C04 09/14/2010
14:7:40 Page 126
(or gaussian) distribution.
4 Much of the existing theory of statistics was developed using this
distribution. It is particularly suited to describing the behavior of the continuous random variables
common to engineering measurements. The normal distribution predicts that the scatter seen in a
measured data set will be distributed symmetrically about some central tendency. Its shape is the
familiar bell curve, as seen in Table 4.2.
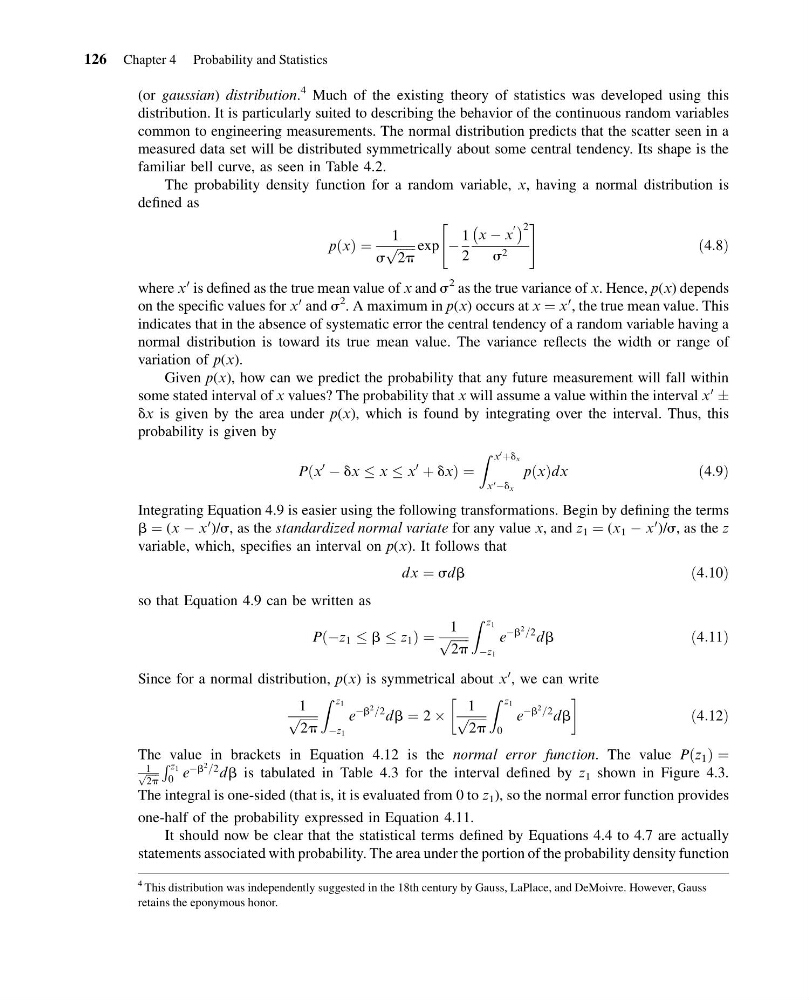
The probability density function for a random variable, x, having a normal distribution is
defined as
p x
ð Þ ¼
1
s
ffiffiffiffiffiffi
2p
p exp À
1
2
x À x
0
À
Á 2
s 2
"
#
ð4:8Þ
where x
0 is defined as the true mean value of x and s
2 as the true variance of x. Hence, p(x) depends
on the specific values for x
0 and s
2 . A maximum in p(x) occurs at x ¼ x
0 , the true mean value. This
indicates that in the absence of systematic error the central tendency of a random variable having a
normal distribution is toward its true mean value. The variance reflects the width or range of
variation of p(x).
Given p(x), how can we predict the probability that any future measurement will fall within
some stated interval of x values? The probability that x will assume a value within the interval x
0
Æ
dx is given by the area under p(x), which is found by integrating over the interval. Thus, this
probability is given by
P x
0
À dx x x
0
þ dx
ð
Þ ¼
Z x
0 þd x
x 0 Àd x
pðxÞdx
ð4:9Þ
Integrating Equation 4.9 is easier using the following transformations. Begin by defining the terms
b ¼ (x À x
0 )/s, as the standardized normal variate for any value x, and z 1 ¼ (x 1 À x
0 )/s, as the z
variable, which, specifies an interval on p(x). It follows that
dx ¼ sdb
ð4:10Þ
so that Equation 4.9 can be written as
P Àz 1 b z 1
ð
Þ¼
1
ffiffiffiffiffiffi
2p
p
Z z 1
Àz 1
e
Àb
2 =2
db
ð4:11Þ
Since for a normal distribution, p(x) is symmetrical about x
0 , we can write
1
ffiffiffiffiffiffi
2p
p
Z z 1
Àz 1
e
Àb
2 =2
db ¼ 2 Â
1
ffiffiffiffiffiffi
2p
p
Z z 1
0
e
Àb
2 =2
db
!
ð4:12Þ
The value in brackets in Equation 4.12 is the normal error function. The value Pðz 1 Þ ¼
1 ffiffiffiffi
2p
p
R z 1
0 e
Àb
2 =2
db is tabulated in Table 4.3 for the interval defined by z 1 shown in Figure 4.3.
The integral is one-sided (that is, it is evaluated from 0 to z 1 ), so the normal error function provides
one-half of the probability expressed in Equation 4.11.
It should now be clear that the statistical terms defined by Equations 4.4 to 4.7 are actually
statements associated with probability. The area under the portion of the probability density function
4 This distribution was independently suggested in the 18th century by Gauss, LaPlace, and DeMoivre. However, Gauss
retains the eponymous honor.
126 Chapter 4 Probability and Statistics