

5 Conclusions
A WLSSVR method with GGP-based sequential sampling was developed to overcome
the difficulty in approximating the nonlinear region of the failure surface in this paper.
This method provides an efficient way for calculating the probability of failure using
only a small number of training samples. The results show that the global approximate
quality of application example is improved.
Acknowledgements. This work was supported by National Natural Science Foundation of
China under Grant No. 61701503.
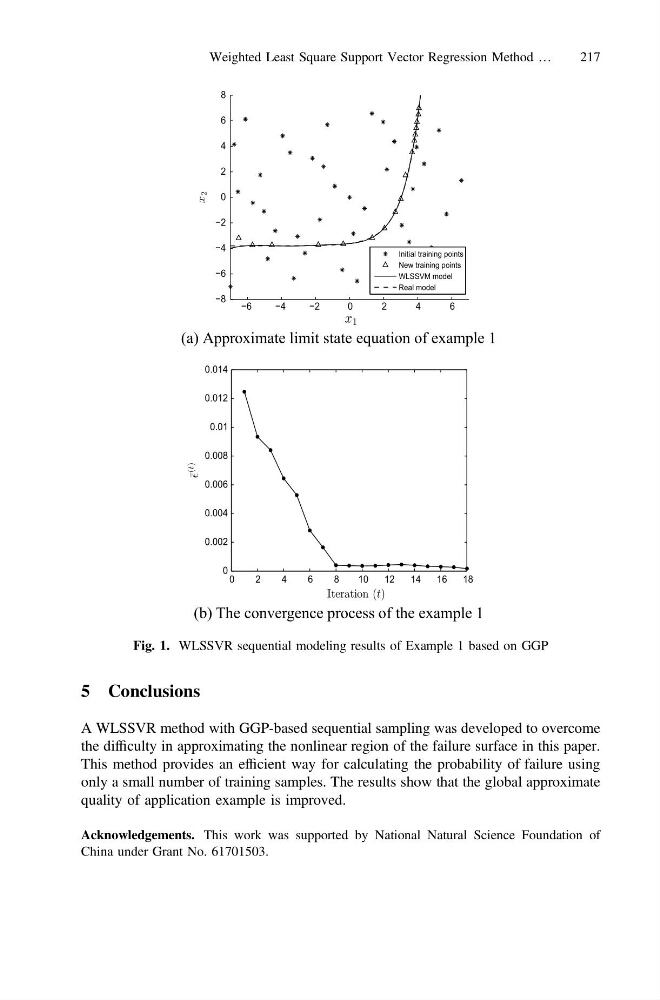
(b) The convergence process of the example 1
0
2
4
6
8
10
12
14
16
18
0
0.002
0.004
0.006
0.008
0.01
0.012
0.014
Iteration (t)
¯
(t)
(a) Approximate limit state equation of example 1
−6
−4
−2
0
2
4
6
−8
−6
−4
−2
0
2
4
6
8
x 1
x
2
Initial training points
New training points
WLSSVM model
Real model
Fig. 1. WLSSVR sequential modeling results of Example 1 based on GGP
Weighted Least Square Support Vector Regression Method …
217