

534
9 Variational Principles in Mechanics and Their Applications
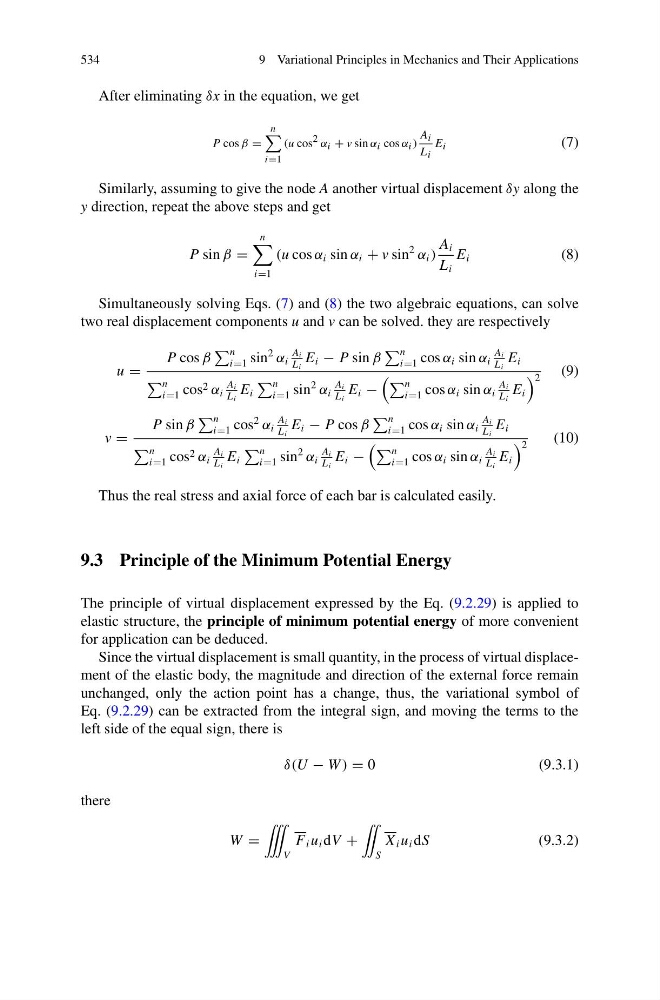
After eliminating δx in the equation, we get
P cos β =
n
i=1
(u cos 2 α i + v sin α i cos α i )
A i
L i
E i
(7)
Similarly, assuming to give the node A another virtual displacement δy along the
y direction, repeat the above steps and get
P sin β =
n
i=1
(u cos α i sin α i + v sin
2
α i )
A i
L i
E i
(8)
Simultaneously solving Eqs. (7) and (8) the two algebraic equations, can solve
two real displacement components u and v can be solved. they are respectively
u =
P cos β
n
i=1 sin
2
α i
A i
L i
E i − P sin β
n
i=1 cos α i sin α i
A i
L i
E i
n
i=1 cos 2 α i
A i
L i
E i
n
i=1 sin
2
α i
A i
L i
E i −
n
i=1 cos α i sin α i
A i
L i
E i
2 (9)
v =
P sin β
n
i=1 cos
2
α i
A i
L i
E i − P cos β
n
i=1 cos α i sin α i
A i
L i
E i
n
i=1 cos 2 α i
A i
L i
E i
n
i=1 sin
2
α i
A i
L i
E i −
n
i=1 cos α i sin α i
A i
L i
E i
2
(10)
Thus the real stress and axial force of each bar is calculated easily.
9.3 Principle of the Minimum Potential Energy
The principle of virtual displacement expressed by the Eq. (9.2.29) is applied to
elastic structure, the principle of minimum potential energy of more convenient
for application can be deduced.
Since the virtual displacement is small quantity, in the process of virtual displacement of the elastic body, the magnitude and direction of the external force remain
unchanged, only the action point has a change, thus, the variational symbol of
Eq. (9.2.29) can be extracted from the integral sign, and moving the terms to the
left side of the equal sign, there is
δ(U − W ) = 0
(9.3.1)
there
W =
˚
V
F i u i dV +
¨
S
X i u i dS
(9.3.2)