

400
10 Dynamic Direct Stiffness Method
Y
(L n ) = −
M n
2E n I n λ n
(coth λ n L n − cot λ n L n )
(10.24)
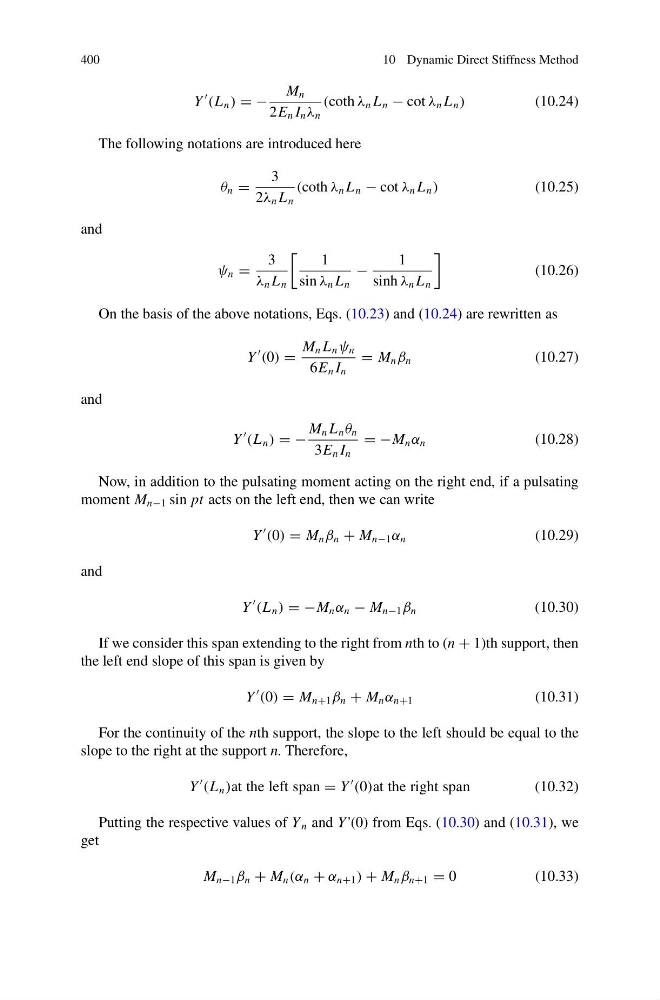
The following notations are introduced here
θ n =
3
2λ n L n
(coth λ n L n − cot λ n L n )
(10.25)
and
ψ n =
3
λ n L n
1
sin λ n L n
−
1
sinh λ n L n
(10.26)
On the basis of the above notations, Eqs. (10.23) and (10.24) are rewritten as
Y
(0) =
M n L n ψ n
6E n I n
= M n β n
(10.27)
and
Y
(L n ) = −
M n L n θ n
3E n I n
= −M n α n
(10.28)
Now, in addition to the pulsating moment acting on the right end, if a pulsating
moment M n−1 sin pt acts on the left end, then we can write
Y
(0) = M n β n + M n−1 α n
(10.29)
and
Y
(L n ) = −M n α n − M n−1 β n
(10.30)
If we consider this span extending to the right from nth to (n + 1)th support, then
the left end slope of this span is given by
Y
(0) = M n+1 β n + M n α n+1
(10.31)
For the continuity of the nth support, the slope to the left should be equal to the
slope to the right at the support n. Therefore,
Y
(L n )at the left span = Y
(0)at the right span
(10.32)
Putting the respective values of Y n and Y’(0) from Eqs. (10.30) and (10.31), we
get
M n−1 β n + M n (α n + α n+1 ) + M n β n+1 = 0
(10.33)