

24
2 Free Vibration of Single Degree of Freedom System
T =
2π
p
=
2π
18.645
= 0.337 s
The system can be idealised into a spring–mass system, and the equation of motion
is given by Eq. (2.11).
x = x 0 cos pt +
˙
x 0
p
sin pt
= 25 cos 18.645 t +
25
18.645
sin 18.645 t
= A cos (18.645t− ∈)
where
A =
(25) 2 +
25
18.645
2
= 25.04 mm
The amplitude of the motion is 25.04 mm
∈= tan
− 1 ˙
x 0
px 0
[Eq. (2.14)]
= tan
− 1
25
18.645 × 25
= 0.054 rad
At t =1 s, the displacement is given by
x = 25.04 cos (18.645 − 0.054) = 24.21 mm
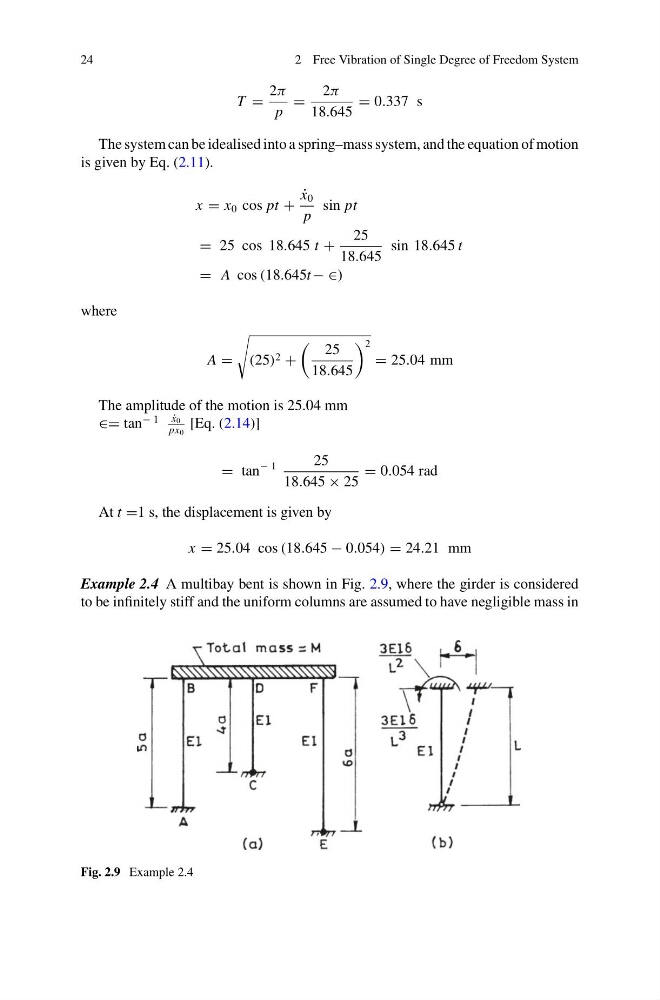
Example 2.4 A multibay bent is shown in Fig. 2.9, where the girder is considered
to be infinitely stiff and the uniform columns are assumed to have negligible mass in
Fig. 2.9 Example 2.4