

5 Stable Structures, Hilbert Sectors, Phases
27
Thus for s = 3 the proof is completed. For s = 1, 2 the convergence of the sum over
α is guaranteed by the properties which characterize the class of potentials under
consideration.
Lemma 5.4 For ϕ 0 ∈ L
∞
(R
s
), the lower bound condition for the potential, (4.13),
implies that (5.11) holds.
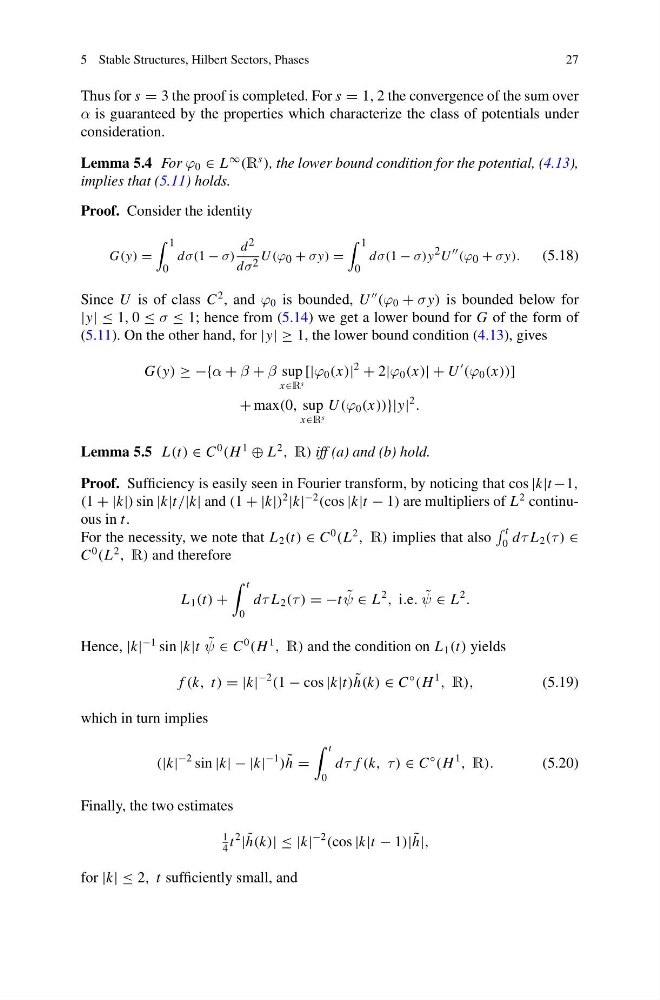
Proof. Consider the identity
G(y) =
1
0
dσ(1 − σ)
d 2
dσ 2 U (ϕ 0 + σ y) =
1
0
dσ(1 − σ)y 2 U (ϕ 0 + σ y).
(5.18)
Since U is of class C
2 , and ϕ 0 is bounded, U
(ϕ 0 + σ y) is bounded below for
|y| ≤ 1, 0 ≤ σ ≤ 1; hence from (5.14) we get a lower bound for G of the form of
(5.11). On the other hand, for |y| ≥ 1, the lower bound condition (4.13), gives
G(y) ≥ −{α + β + β sup
x∈R s
[|ϕ 0 (x)|
2
+ 2|ϕ 0 (x)| + U
(ϕ 0 (x))]
+ max(0, sup
x∈R s
U (ϕ 0 (x))}|y|
2
.
Lemma 5.5 L(t) ∈ C
0
(H
1
⊕ L
2
, R) iff (a) and (b) hold.
Proof. Sufficiency is easily seen in Fourier transform, by noticing that cos |k|t −1,
(1 + |k|) sin |k|t/|k| and (1 + |k|)
2
|k|
−2
(cos |k|t − 1) are multipliers of L
2 continuous in t.
For the necessity, we note that L 2 (t) ∈ C
0
(L
2
, R) implies that also
t
0 dτ L 2 (τ ) ∈
C
0
(L
2
, R) and therefore
L 1 (t) +
t
0
dτ L 2 (τ ) = −t ˜
ψ ∈ L
2
, i.e. ˜
ψ ∈ L
2
.
Hence, |k|
−1 sin |k|t ˜
ψ ∈ C
0
(H
1
, R) and the condition on L 1 (t) yields
f (k, t) = |k|
−2
(1 − cos |k|t) ˜
h(k) ∈ C
◦
(H
1
, R),
(5.19)
which in turn implies
(|k|
−2 sin |k| − |k|
−1
) ˜
h =
t
0
dτ f (k, τ ) ∈ C
◦
(H
1
, R).
(5.20)
Finally, the two estimates
1
4
t
2
| ˜
h(k)| ≤ |k|
−2
(cos |k|t − 1)| ˜
h|,
for |k| ≤ 2, t sufficiently small, and