

17.3 ∗ Appendix: The Infinite Volume Dynamics for Short-Range Spin Interactions
117
We shall first consider the case of finite range and sketch the proof
98 that, ∀A ∈ A L ,
α
V
t (A) converges in norm. This implies that the norm limit α t is norm preserving:
||α t (A)|| = ||A|| and therefore it defines an automorphism of A L . Thus, α t can be
extended to the norm closure A of A L , the extension is norm preserving and it leaves
A stable.
99 Hence, the dynamics exists as an automorphism of A.
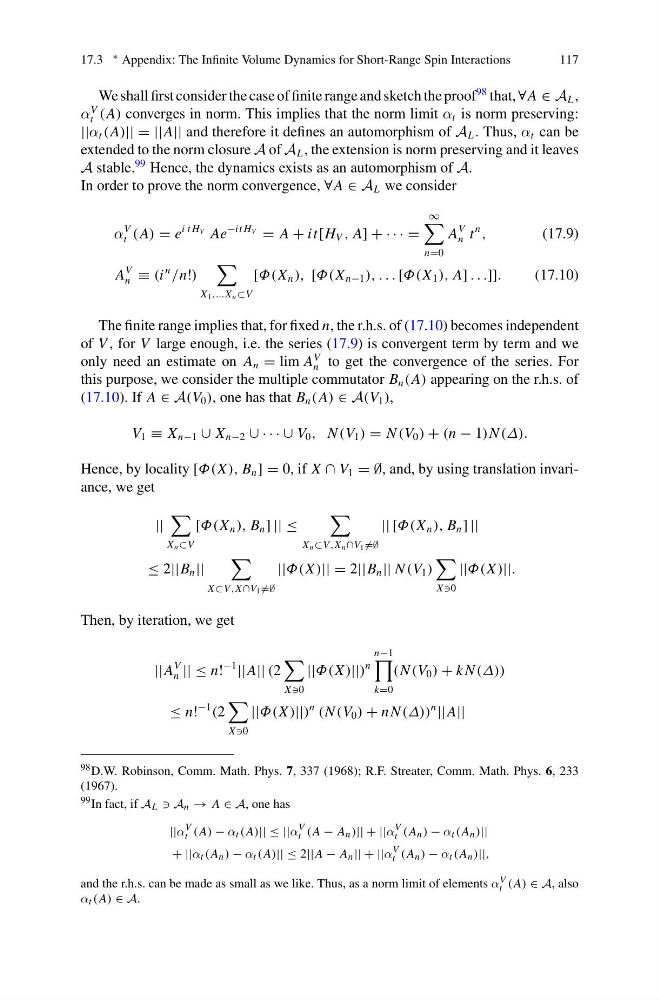
In order to prove the norm convergence, ∀A ∈ A L we consider
α
V
t (A) = e
i t H V Ae
−it H V = A + it[H V , A] + · · · =
∞
n=0
A
V
n t
n
,
(17.9)
A
V
n ≡ (i
n
/n!)
X 1 ,...X n ⊂V
[Φ(X n ), [Φ(X n−1 ), . . . [Φ(X 1 ), A] . . .]].
(17.10)
The finite range implies that, for fixed n, the r.h.s. of (17.10) becomes independent
of V , for V large enough, i.e. the series (17.9) is convergent term by term and we
only need an estimate on A n = lim A
V
n to get the convergence of the series. For
this purpose, we consider the multiple commutator B n (A) appearing on the r.h.s. of
(17.10). If A ∈ A(V 0 ), one has that B n (A) ∈ A(V 1 ),
V 1 ≡ X n−1 ∪ X n−2 ∪ · · · ∪ V 0 , N (V 1 ) = N (V 0 ) + (n − 1)N (Δ).
Hence, by locality [Φ(X ), B n ] = 0, if X ∩ V 1 = ∅, and, by using translation invariance, we get
||
X n ⊂V
[Φ(X n ), B n ] || ≤
X n ⊂V,X n ∩V 1 =∅
|| [Φ(X n ), B n ] ||
≤ 2||B n ||
X ⊂V,X ∩V 1 =∅
||Φ(X )|| = 2||B n || N (V 1 )
X 0
||Φ(X )||.
Then, by iteration, we get
||A
V
n || ≤ n!
−1
||A|| (2
X 0
||Φ(X )||)
n
n−1
k=0
(N (V 0 ) + k N (Δ))
≤ n!
−1
(2
X 0
||Φ(X )||)
n
(N (V 0 ) + n N (Δ))
n
||A||
98 D.W. Robinson, Comm. Math. Phys. 7, 337 (1968); R.F. Streater, Comm. Math. Phys. 6, 233
(1967).
99 In fact, if A L A n → A ∈ A, one has
||α
V
t (A) − α t (A)|| ≤ ||α
V
t (A − A n )|| + ||α
V
t (A n ) − α t (A n )||
+ ||α t (A n ) − α t (A)|| ≤ 2||A − A n || + ||α
V
t (A n ) − α t (A n )||,
and the r.h.s. can be made as small as we like. Thus, as a norm limit of elements α V
t (A) ∈ A, also
α t (A) ∈ A.