

192
6 Two-Dimensional Problems in Elasticity …
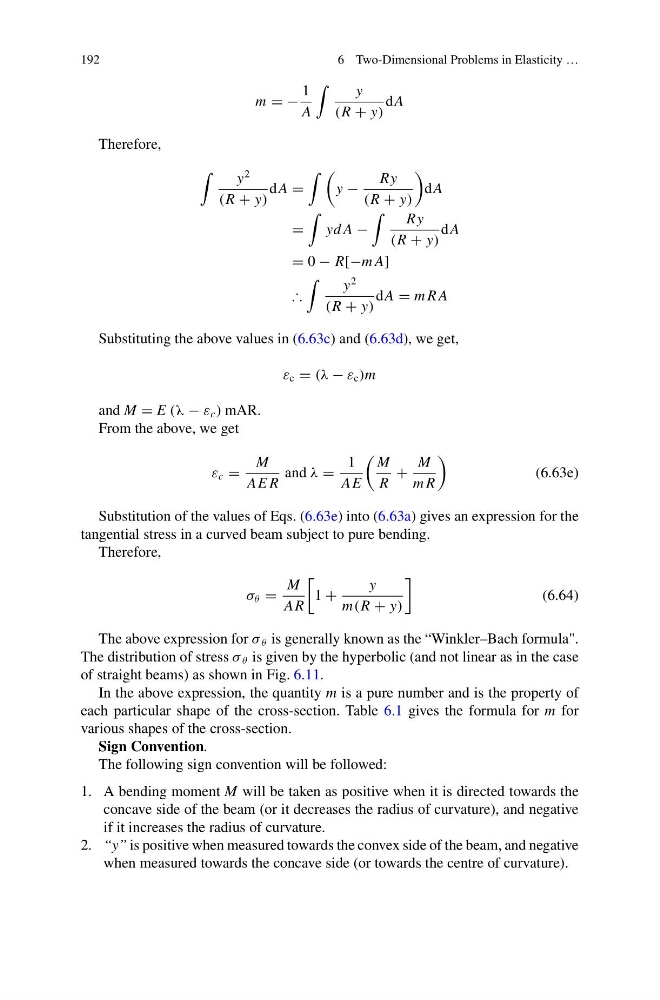
m = −
1
A
y
(R + y)
dA
Therefore,
y
2
(R + y)
dA =
y −
Ry
(R + y)
dA
=
yd A −
Ry
(R + y)
dA
= 0 − R[−m A]
∴
y
2
(R + y)
dA = m R A
Substituting the above values in (6.63c) and (6.63d), we get,
ε c = (λ − ε c )m
and M = E (λ − ε c ) mAR.
From the above, we get
ε c =
M
AE R
and λ =
1
AE
M
R
+
M
m R
(6.63e)
Substitution of the values of Eqs. (6.63e) into (6.63a) gives an expression for the
tangential stress in a curved beam subject to pure bending.
Therefore,
σ θ =
M
AR
1 +
y
m(R + y)
(6.64)
The above expression for σ θ is generally known as the “Winkler–Bach formula".
The distribution of stress σ θ is given by the hyperbolic (and not linear as in the case
of straight beams) as shown in Fig. 6.11.
In the above expression, the quantity m is a pure number and is the property of
each particular shape of the cross-section. Table 6.1 gives the formula for m for
various shapes of the cross-section.
Sign Convention.
The following sign convention will be followed:
1. A bending moment M will be taken as positive when it is directed towards the
concave side of the beam (or it decreases the radius of curvature), and negative
if it increases the radius of curvature.
2. “y” is positive when measured towards the convex side of the beam, and negative
when measured towards the concave side (or towards the centre of curvature).