

52
4 Observer Space-Time Formalism
4.1 Fundamental Observables
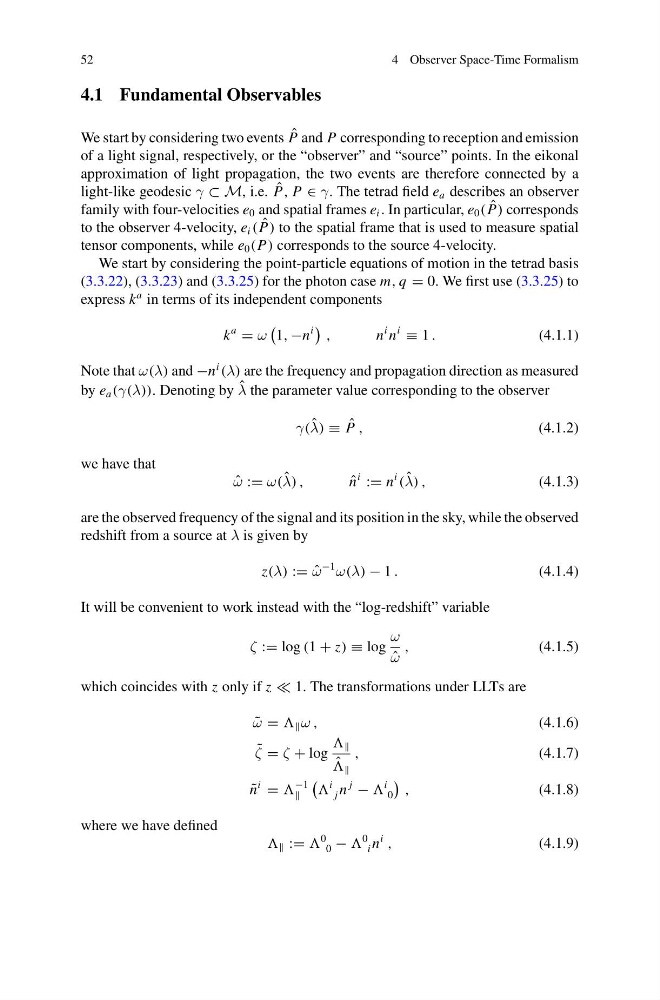
We start by considering two events ˆ
P and P corresponding to reception and emission
of a light signal, respectively, or the “observer” and “source” points. In the eikonal
approximation of light propagation, the two events are therefore connected by a
light-like geodesic γ ⊂ M, i.e. ˆ
P, P ∈ γ. The tetrad field e a describes an observer
family with four-velocities e 0 and spatial frames e i . In particular, e 0 ( ˆ
P) corresponds
to the observer 4-velocity, e i ( ˆ
P) to the spatial frame that is used to measure spatial
tensor components, while e 0 (P) corresponds to the source 4-velocity.
We start by considering the point-particle equations of motion in the tetrad basis
(3.3.22), (3.3.23) and (3.3.25) for the photon case m, q = 0. We first use (3.3.25) to
express k
a in terms of its independent components
k
a
= ω
1, −n
i
,
n
i n
i
≡ 1 .
(4.1.1)
Note that ω(λ) and −n
i
(λ) are the frequency and propagation direction as measured
by e a (γ(λ)). Denoting by ˆ
λ the parameter value corresponding to the observer
γ( ˆ
λ) ≡ ˆ
P ,
(4.1.2)
we have that
ˆ
ω := ω( ˆ
λ) ,
ˆ
n
i
:= n
i
( ˆ
λ) ,
(4.1.3)
are the observed frequency of the signal and its position in the sky, while the observed
redshift from a source at λ is given by
z(λ) := ˆ
ω
−1
ω(λ) − 1 .
(4.1.4)
It will be convenient to work instead with the “log-redshift” variable
ζ := log (1 + z) ≡ log
ω
ˆ
ω
,
(4.1.5)
which coincides with z only if z 1. The transformations under LLTs are
˜
ω = ω ,
(4.1.6)
˜
ζ = ζ + log
ˆ
,
(4.1.7)
˜
n
i
=
−1
i
j n
j
−
i
0
,
(4.1.8)
where we have defined
:=
0
0 −
0
i n
i
,
(4.1.9)