

14
2 Motivation
ing the “background” (or “unlensed”) ( ¯
θ, ¯
φ) and “deflected” (or “lensed”) (θ, φ)
angular positions in the sky. As we just saw, however, the (θ, φ) are not the observed
angles of some observer, because now the metric at the observer also includes fluctuations, so the deflections (δθ, δφ) are ambiguous.
2.2 Advantages of the Tetrad Formulation of Differential
Geometry
Although the introduction of a tetrad ˆ
e a at the observer point is technically sufficient
to define all the desired observables in a coordinate and background-independent way,
it has the inelegant aspect of arising as some extra manipulation, i.e. the translation
between the T ˆ
P M bases ˆ
e a and ∂ μ | ˆ
P . A simple way around the problem is to consider
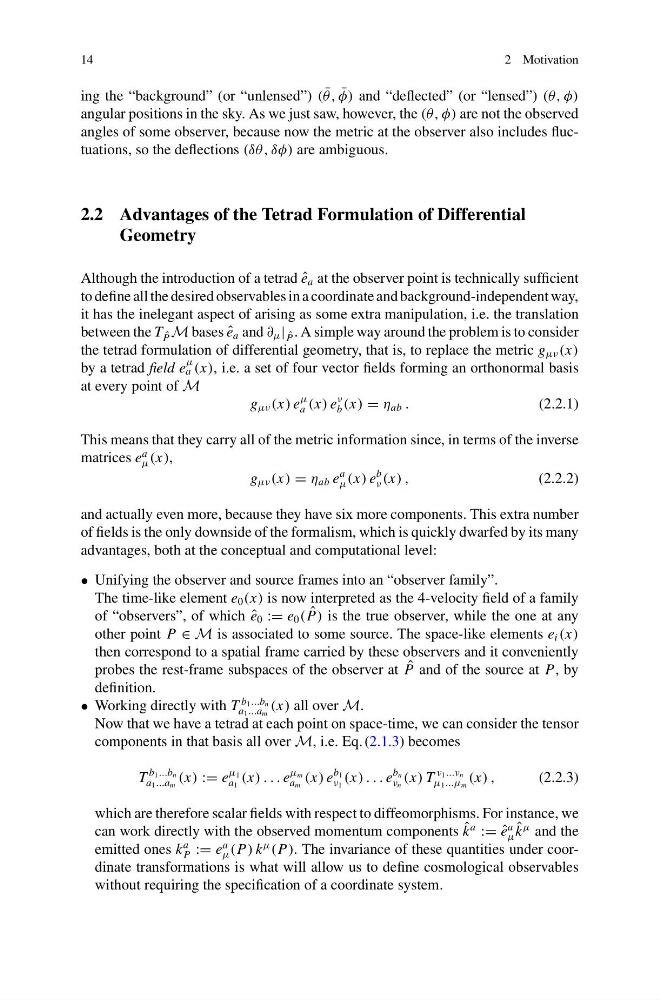
the tetrad formulation of differential geometry, that is, to replace the metric g μν (x)
by a tetrad field e
μ
a (x), i.e. a set of four vector fields forming an orthonormal basis
at every point of M
g μν (x) e
μ
a (x) e
ν
b (x) = η ab .
(2.2.1)
This means that they carry all of the metric information since, in terms of the inverse
matrices e
a
μ (x),
g μν (x) = η ab e
a
μ (x) e
b
ν (x) ,
(2.2.2)
and actually even more, because they have six more components. This extra number
of fields is the only downside of the formalism, which is quickly dwarfed by its many
advantages, both at the conceptual and computational level:
• Unifying the observer and source frames into an “observer family”.
The time-like element e 0 (x) is now interpreted as the 4-velocity field of a family
of “observers”, of which ˆ
e 0 := e 0 ( ˆ
P) is the true observer, while the one at any
other point P ∈ M is associated to some source. The space-like elements e i (x)
then correspond to a spatial frame carried by these observers and it conveniently
probes the rest-frame subspaces of the observer at ˆ
P and of the source at P, by
definition.
• Working directly with T
b 1 ...b n
a 1 ...a m
(x) all over M.
Now that we have a tetrad at each point on space-time, we can consider the tensor
components in that basis all over M, i.e. Eq. (2.1.3) becomes
T
b 1 ...b n
a 1 ...a m
(x) := e
μ 1
a 1
(x) . . . e
μ m
a m
(x) e
b 1
ν 1
(x) . . . e
b n
ν n
(x) T
ν 1 ...ν n
μ 1 ...μ m
(x) ,
(2.2.3)
which are therefore scalar fields with respect to diffeomorphisms. For instance, we
can work directly with the observed momentum components ˆ
k
a
:= ˆ
e
a
μ
ˆ
k
μ and the
emitted ones k
a
P := e
a
μ (P) k
μ
(P). The invariance of these quantities under coordinate transformations is what will allow us to define cosmological observables
without requiring the specification of a coordinate system.