

132
6 Dynamics of Quantum Mechanical Macroscopic Systems
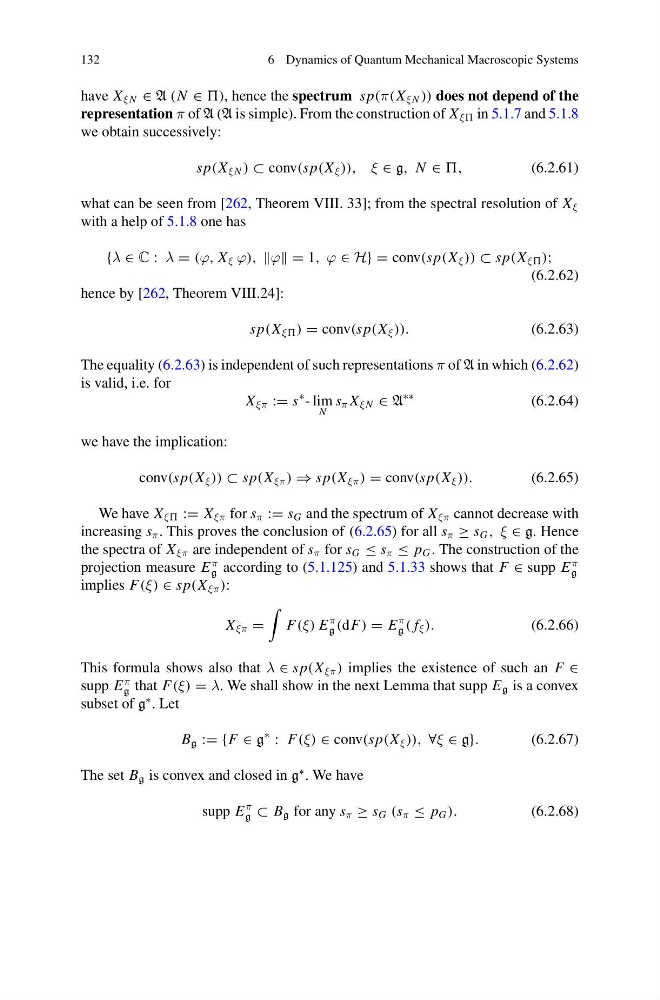
have X ξ N ∈ A (N ∈ ), hence the spectrum sp(π(X ξ N )) does not depend of the
representation π of A (A is simple). From the construction of X ξ in 5.1.7 and 5.1.8
we obtain successively:
sp(X ξ N ) ⊂ conv(sp(X ξ )), ξ ∈ g, N ∈ ,
(6.2.61)
what can be seen from [262, Theorem VIII. 33]; from the spectral resolution of X ξ
with a help of 5.1.8 one has
{λ ∈ C : λ = (ϕ, X ξ ϕ), ϕ = 1, ϕ ∈ H} = conv(sp(X ξ )) ⊂ sp(X ξ );
(6.2.62)
hence by [262, Theorem VIII.24]:
sp(X ξ ) = conv(sp(X ξ )).
(6.2.63)
The equality (6.2.63) is independent of such representations π of A in which (6.2.62)
is valid, i.e. for
X ξπ := s
∗ - lim
N
s π X ξ N ∈ A
∗∗
(6.2.64)
we have the implication:
conv(sp(X ξ )) ⊂ sp(X ξπ ) ⇒ sp(X ξπ ) = conv(sp(X ξ )).
(6.2.65)
We have X ξ := X ξπ for s π := s G and the spectrum of X ξπ cannot decrease with
increasing s π . This proves the conclusion of (6.2.65) for all s π ≥ s G , ξ ∈ g. Hence
the spectra of X ξπ are independent of s π for s G ≤ s π ≤ p G . The construction of the
projection measure E
π
g according to (5.1.125) and 5.1.33 shows that F ∈ supp E
π
g
implies F(ξ) ∈ sp(X ξπ ):
X ξπ =
F(ξ) E
π
g (dF) = E
π
g ( f ξ ).
(6.2.66)
This formula shows also that λ ∈ sp(X ξπ ) implies the existence of such an F ∈
supp E
π
g that F(ξ) = λ. We shall show in the next Lemma that supp E g is a convex
subset of g
∗ . Let
B g := {F ∈ g
∗
: F(ξ) ∈ conv(sp(X ξ )), ∀ξ ∈ g}.
(6.2.67)
The set B g is convex and closed in g
∗ . We have
supp E
π
g ⊂ B g for any s π ≥ s G (s π ≤ p G ).
(6.2.68)