

The other termination conditions with regards to search of thread propagation is
to check all dependent vertexes. There is no doubt that only tracing of all elements
provide a 100% cover for threat checking. Unfortunately, this termination condition
is not viable as it becomes network scale-dependent. It is important to note that the
probability matrix associated with Fig. 18.2 is not Markovian because the sum of
probabilities on the edges at each node may not be equal to 1.
18.3.2 Treat Propagation: Tracing and Handling
Algorithms
The threat propagation from one element to another through the edges, according to
Tracing algorithm is defined as П (p i, j ). Here, (p i, j ) represents the probability of
threat propagation from node i to node j through the corresponding edge. Note that
the treat might spread through a series of other nodes.
Therefore, when there are several paths leading from node i to node j all possible
cumulative distributions are ranked and all the nodes along the paths are included in
the group of suspected nodes.
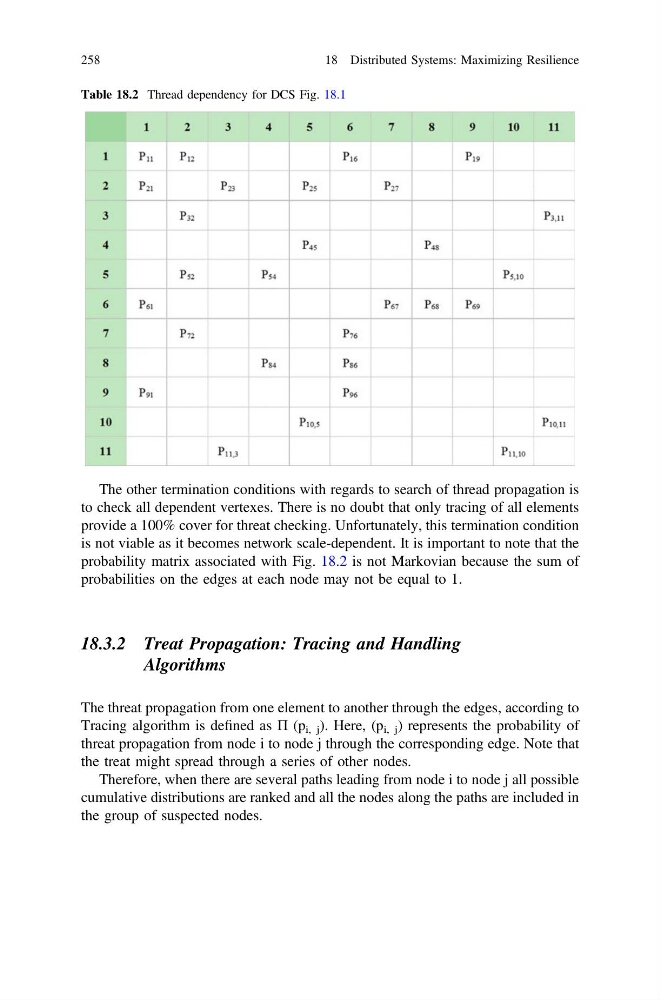
Table 18.2 Thread dependency for DCS Fig. 18.1
258
18 Distributed Systems: Maximizing Resilience