

42
3 Geometrically Nonlinear Theories
The derivative of the covariant and contravariant base vectors of point P , a α and
n, with respect to Θ
β can be obtained as
a α,β = Γ
δ
αβ a δ + b αβ n ,
(3.23)
a
α ,β = −Γ
α
δβ a
δ
+ b
α
β n ,
(3.24)
n ,β = −b
δ
β a δ = −b λβ a
λ
.
(3.25)
Here, b αβ and b
α
β are the covariant and mixed components of the curvature tensor,
respectively, which can be calculated by
b αβ = a α,β · n = −a α · n ,β ,
(3.26)
b
α
β = a
α ,β · n = −a
α
· n ,β .
(3.27)
The relations between the covariant and mixed components of the curvature tensor
can be obtained as
b
λ
α = a
βλ b αβ .
(3.28)
3.2.4 Quantities in Deformed Configurations
From Fig. 3.1, two configurations are defined in mathematical theory description,
i.e. deformed and undeformed configuration. The quantities introduced in the above
subsections are in the undeformed configuration. Using the same notations, but with
an overbar, are used for the base vectors and geometric quantities in the deformed
configuration, which is shown in the middle part of Fig. 3.1. Thus, the base vectors
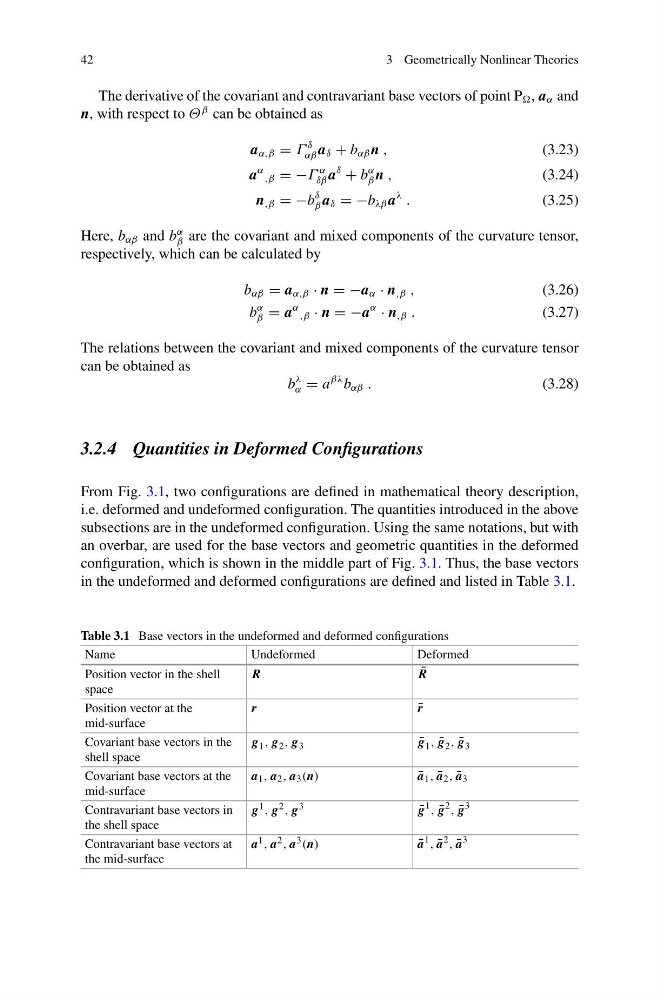
in the undeformed and deformed configurations are defined and listed in Table 3.1.
Table 3.1 Base vectors in the undeformed and deformed configurations
Name
Undeformed
Deformed
Position vector in the shell
space
R
¯
R
Position vector at the
mid-surface
r
¯
r
Covariant base vectors in the
shell space
g 1 , g 2 , g 3
¯
g 1 , ¯
g 2 , ¯
g 3
Covariant base vectors at the
mid-surface
a 1 , a 2 , a 3 (n)
¯
a 1 , ¯
a 2 , ¯
a 3
Contravariant base vectors in
the shell space
g 1 , g 2 , g 3
¯
g
1 , ¯
g
2 , ¯
g
3
Contravariant base vectors at
the mid-surface
a 1 , a 2 , a 3 (n)
¯
a
1 , ¯
a
2 , ¯
a
3