

Appendix A
Geometric Quantities
A.1 Plate Structure
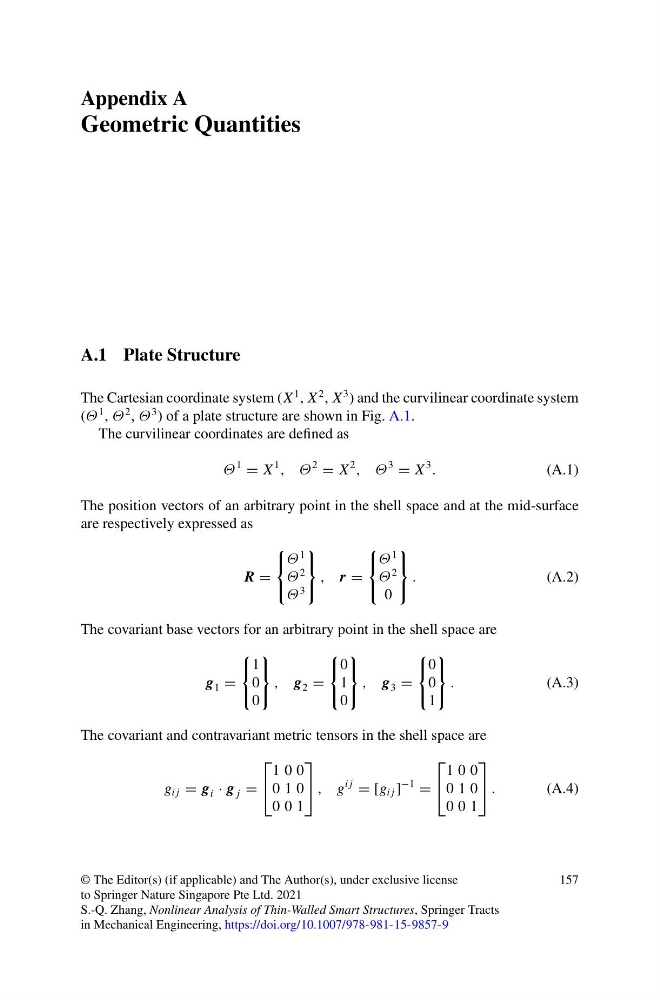
The Cartesian coordinate system (X
1 , X
2 , X
3 ) and the curvilinear coordinate system
(Θ
1 , Θ
2 , Θ
3 ) of a plate structure are shown in Fig. A.1.
The curvilinear coordinates are defined as
Θ
1
= X
1
, Θ
2
= X
2
, Θ
3
= X
3
.
(A.1)
The position vectors of an arbitrary point in the shell space and at the mid-surface
are respectively expressed as
R =
⎧
⎨
⎩
Θ
1
Θ
2
Θ
3
⎫
⎬
⎭
, r =
⎧
⎨
⎩
Θ
1
Θ
2
0
⎫
⎬
⎭
.
(A.2)
The covariant base vectors for an arbitrary point in the shell space are
g 1 =
⎧
⎨
⎩
1
0
0
⎫
⎬
⎭
, g 2 =
⎧
⎨
⎩
0
1
0
⎫
⎬
⎭
, g 3 =
⎧
⎨
⎩
0
0
1
⎫
⎬
⎭
.
(A.3)
The covariant and contravariant metric tensors in the shell space are
g i j = g i · g j =
⎡
⎣
1 0 0
0 1 0
0 0 1
⎤
⎦ , g
i j
= [g i j ]
−1
=
⎡
⎣
1 0 0
0 1 0
0 0 1
⎤
⎦ .
(A.4)
© The Editor(s) (if applicable) and The Author(s), under exclusive license
to Springer Nature Singapore Pte Ltd. 2021
S.-Q. Zhang, Nonlinear Analysis of Thin-Walled Smart Structures, Springer Tracts
in Mechanical Engineering, https://doi.org/10.1007/978-981-15-9857-9
157