

206
S. Zhan et al.
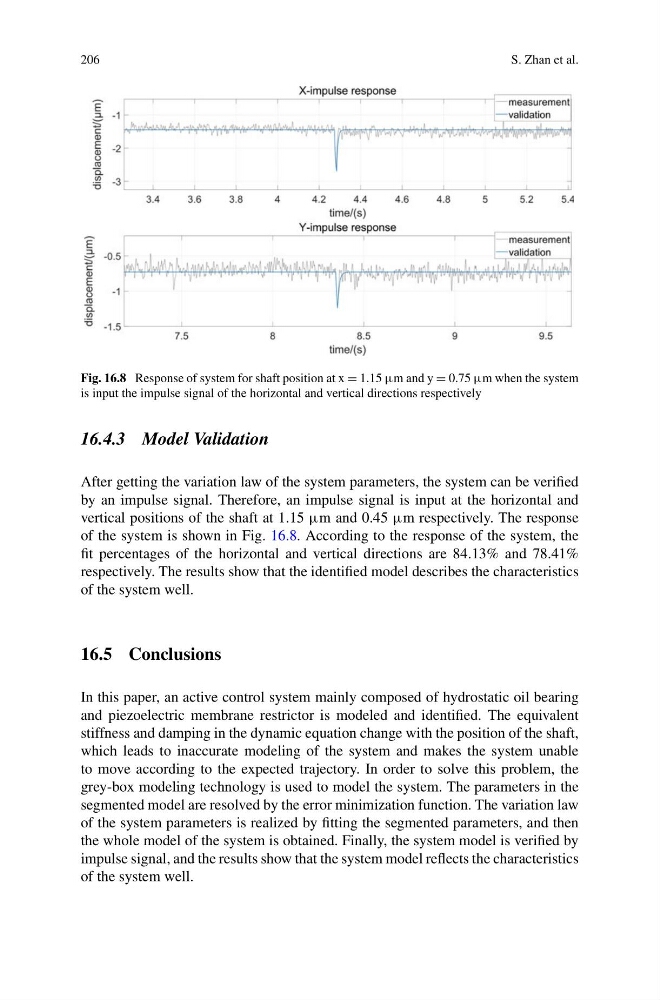
Fig. 16.8 Response of system for shaft position at x = 1.15 μm and y = 0.75 μm when the system
is input the impulse signal of the horizontal and vertical directions respectively
16.4.3 Model Validation
After getting the variation law of the system parameters, the system can be verified
by an impulse signal. Therefore, an impulse signal is input at the horizontal and
vertical positions of the shaft at 1.15 μm and 0.45 μm respectively. The response
of the system is shown in Fig. 16.8. According to the response of the system, the
fit percentages of the horizontal and vertical directions are 84.13% and 78.41%
respectively. The results show that the identified model describes the characteristics
of the system well.
16.5 Conclusions
In this paper, an active control system mainly composed of hydrostatic oil bearing
and piezoelectric membrane restrictor is modeled and identified. The equivalent
stiffness and damping in the dynamic equation change with the position of the shaft,
which leads to inaccurate modeling of the system and makes the system unable
to move according to the expected trajectory. In order to solve this problem, the
grey-box modeling technology is used to model the system. The parameters in the
segmented model are resolved by the error minimization function. The variation law
of the system parameters is realized by fitting the segmented parameters, and then
the whole model of the system is obtained. Finally, the system model is verified by
impulse signal, and the results show that the system model reflects the characteristics
of the system well.