

1.5 Classification of Computer Models
9
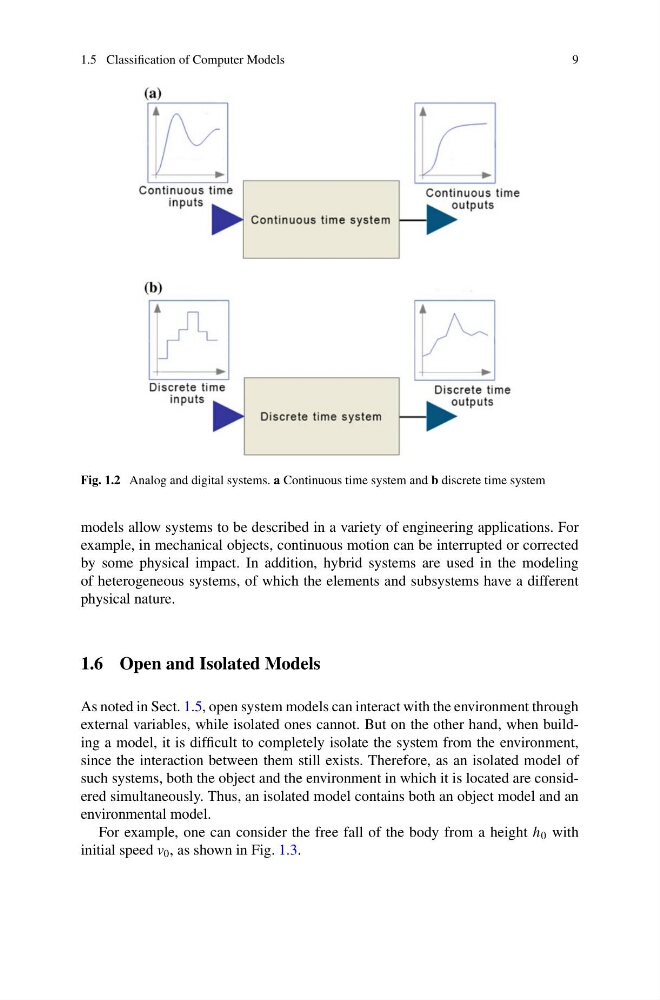
Fig. 1.2 Analog and digital systems. a Continuous time system and b discrete time system
models allow systems to be described in a variety of engineering applications. For
example, in mechanical objects, continuous motion can be interrupted or corrected
by some physical impact. In addition, hybrid systems are used in the modeling
of heterogeneous systems, of which the elements and subsystems have a different
physical nature.
1.6 Open and Isolated Models
As noted in Sect. 1.5, open system models can interact with the environment through
external variables, while isolated ones cannot. But on the other hand, when building a model, it is difficult to completely isolate the system from the environment,
since the interaction between them still exists. Therefore, as an isolated model of
such systems, both the object and the environment in which it is located are considered simultaneously. Thus, an isolated model contains both an object model and an
environmental model.
For example, one can consider the free fall of the body from a height h 0 with
initial speed v 0 , as shown in Fig. 1.3.