

5.8 Mechanical System with Two Springs and a Block
199
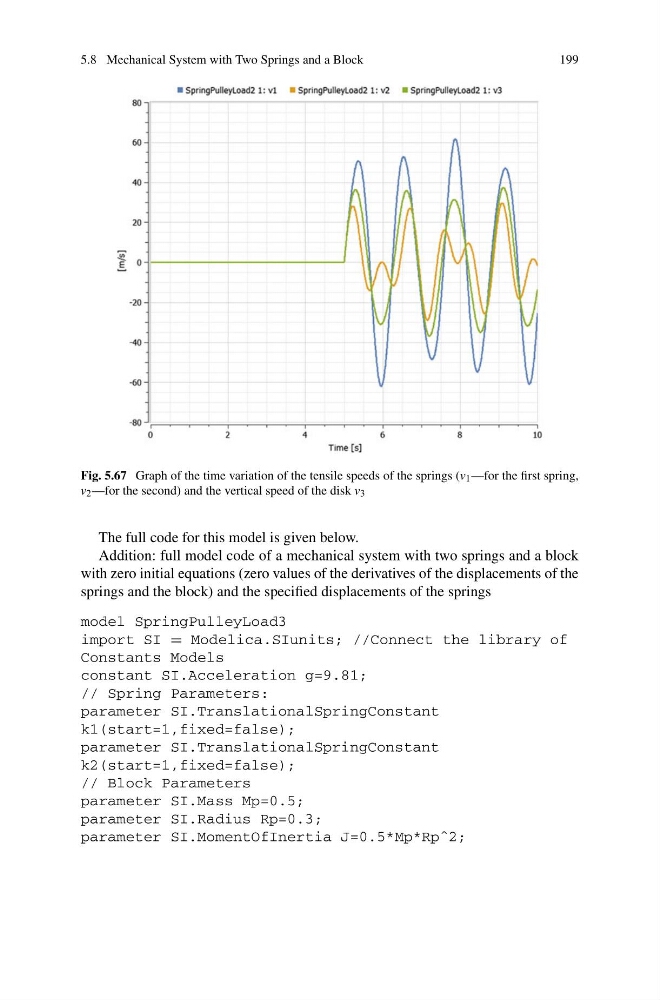
Fig. 5.67 Graph of the time variation of the tensile speeds of the springs (v 1 —for the first spring,
v 2 —for the second) and the vertical speed of the disk v 3
The full code for this model is given below.
Addition: full model code of a mechanical system with two springs and a block
with zero initial equations (zero values of the derivatives of the displacements of the
springs and the block) and the specified displacements of the springs
model SpringPulleyLoad3
import SI = Modelica.SIunits; //Connect the library of
Constants Models
constant SI.Acceleration g=9.81;
// Spring Parameters:
parameter SI.TranslationalSpringConstant
k1(start=1,fixed=false);
parameter SI.TranslationalSpringConstant
k2(start=1,fixed=false);
// Block Parameters
parameter SI.Mass Mp=0.5;
parameter SI.Radius Rp=0.3;
parameter SI.MomentOfInertia J=0.5*Mp*Rpˆ2;