

3.3 Hierarchical Principles of Model Building
115
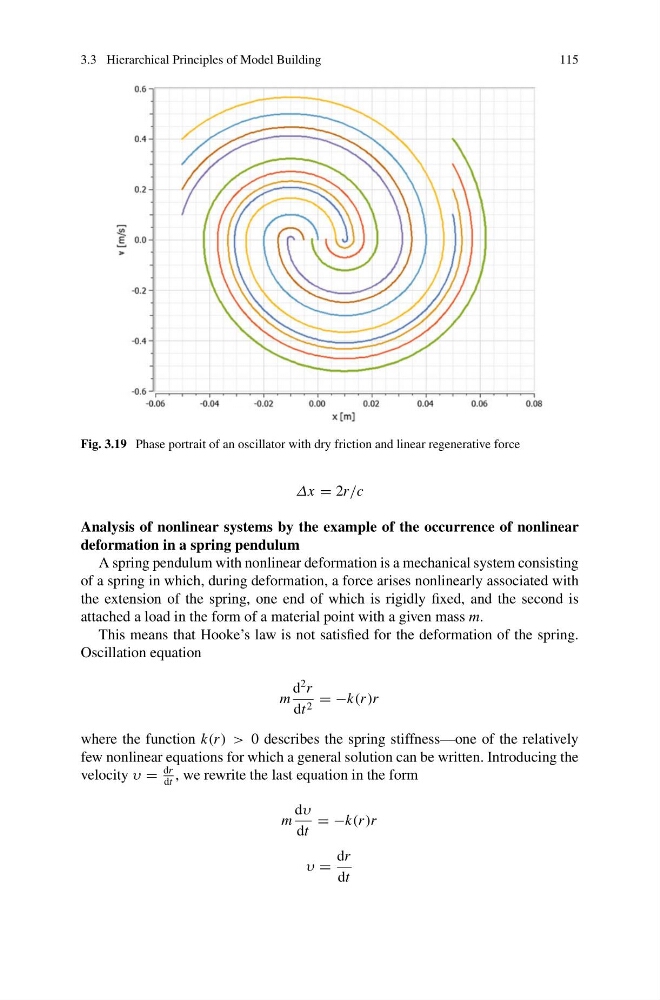
Fig. 3.19 Phase portrait of an oscillator with dry friction and linear regenerative force
Δx = 2r/c
Analysis of nonlinear systems by the example of the occurrence of nonlinear
deformation in a spring pendulum
A spring pendulum with nonlinear deformation is a mechanical system consisting
of a spring in which, during deformation, a force arises nonlinearly associated with
the extension of the spring, one end of which is rigidly fixed, and the second is
attached a load in the form of a material point with a given mass m.
This means that Hooke’s law is not satisfied for the deformation of the spring.
Oscillation equation
m
d
2 r
dt 2 = −k(r )r
where the function k(r ) > 0 describes the spring stiffness—one of the relatively
few nonlinear equations for which a general solution can be written. Introducing the
velocity υ =
dr
dt
, we rewrite the last equation in the form
m
dυ
dt
= −k(r )r
υ =
dr
dt