

8
1 Some Linear Algebra
Definition 1.5.4 Let R be a commutative ring with unit. An R-module M is said to
be free R-module if M is isomorphic to a direct sum of copies of R. In other words,
there exists an index set I such that M =
i∈I
R i , where R i = =b i ∼ = R ( ∼ = as Rmodules) for every i ∈ I. The index set I can be finite or infinite and B = {bi|i ∈ I}
is said to be a basis of M.
The concept of free module will be utilized in the definition of convolutional
codes (see Sect. 7.1).
1.6 Metric Spaces
In the following we recall the concept of metric space.
Definition 1.6.1 A metric space consists of an ordered pair (M, d), where M is a
nonempty set and d is a function d : M × M −→ R such that, ∀ x, y, z ∈ M, the
following conditions are satisfied:
(1) d(x, y) ≥ 0;
(2) d(x, y) = 0 ⇐⇒ x = y;
(3) (Symmetry) d(x, y) = d(y, x);
(4) (Triangle inequality) d(x, z) ≤ d(x, y) + d(y, z).
The function d is called metric (or distance function) on M.
A metric space is a particular case of a topological space. Since this is not the subject
of this book, we will not describe the latter concept here. For the reader who is
interested to learn about topological spaces, we suggest the textbooks [8, 118].
As examples, let us consider the n-dimensional Euclidean space R
n
= {(x 1 , x 2 ,
. . . , x n ), x i ∈ R} and the unitary (sometimes called complex Euclidean n-space) ndimensional space C
n
= {(x 1 , x 2 , . . . , x n ), x i ∈ C}. In the first case, if x = (x 1 , x 2 ,
. . . , x n ) and y = (y 1 , y 2 , . . . , y n ) are vectors in R
n then the Euclidean metric on R
n
is defined as
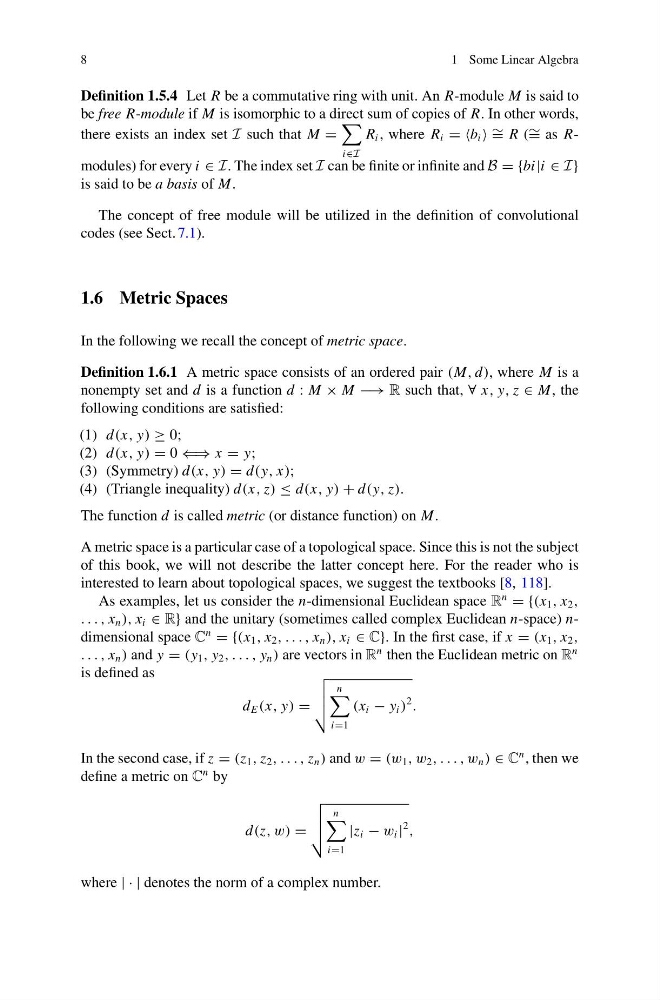
d E (x, y) =
n
i=1
(x i − y i )
2
.
In the second case, if z = (z 1 , z 2 , . . . , z n ) and w = (w 1 , w 2 , . . . , w n ) ∈ C
n , then we
define a metric on C
n by
d(z, w) =
n
i=1
|z i − w i |
2
,
where | · | denotes the norm of a complex number.