

3.7 Boundary Value Problems
149
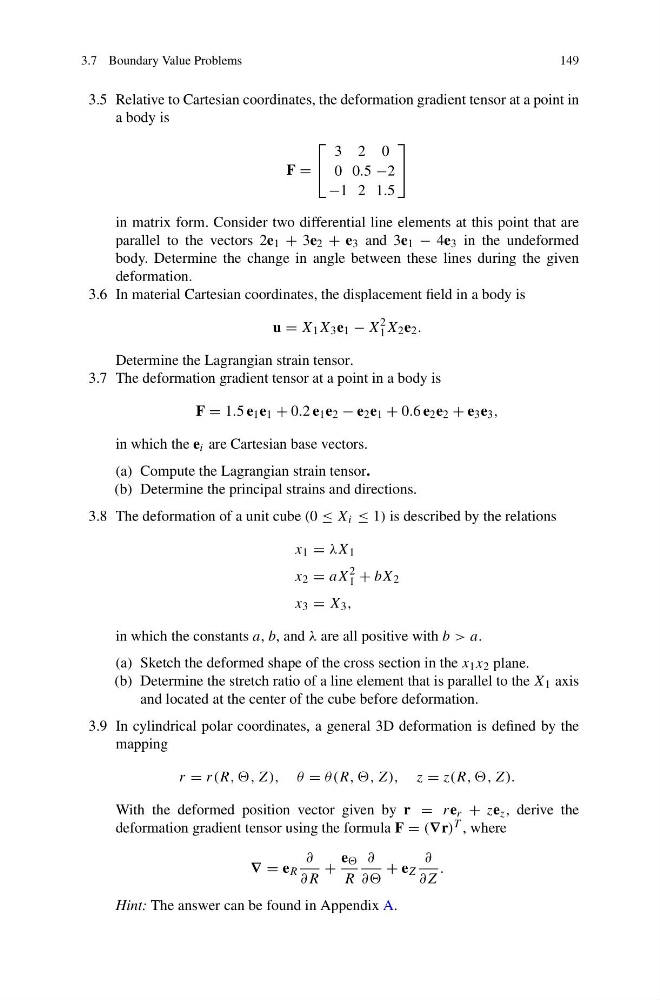
3.5 Relative to Cartesian coordinates, the deformation gradient tensor at a point in
a body is
F =
⎡
⎣
3 2 0
0 0.5 −2
−1 2 1.5
⎤
⎦
in matrix form. Consider two differential line elements at this point that are
parallel to the vectors 2e 1 + 3e 2 + e 3 and 3e 1 − 4e 3 in the undeformed
body. Determine the change in angle between these lines during the given
deformation.
3.6 In material Cartesian coordinates, the displacement field in a body is
u = X 1 X 3 e 1 − X
2
1 X 2 e 2 .
Determine the Lagrangian strain tensor.
3.7 The deformation gradient tensor at a point in a body is
F = 1.5 e 1 e 1 + 0.2 e 1 e 2 − e 2 e 1 + 0.6 e 2 e 2 + e 3 e 3 ,
in which the e i are Cartesian base vectors.
(a) Compute the Lagrangian strain tensor.
(b) Determine the principal strains and directions.
3.8 The deformation of a unit cube (0 ≤ X i ≤ 1) is described by the relations
x 1 = λX 1
x 2 = aX
2
1 + bX 2
x 3 = X 3 ,
in which the constants a, b, and λ are all positive with b > a.
(a) Sketch the deformed shape of the cross section in the x 1 x 2 plane.
(b) Determine the stretch ratio of a line element that is parallel to the X 1 axis
and located at the center of the cube before deformation.
3.9 In cylindrical polar coordinates, a general 3D deformation is defined by the
mapping
r = r(R, ,, Z), θ = θ(R, ,, Z), z = z(R, ,, Z).
With the deformed position vector given by r = re r + ze z , derive the
deformation gradient tensor using the formula F = (∇r) T , where
∇ = e R
∂
∂R
+
e
R
∂
∂∂
+ e Z
∂
∂Z
.
Hint: The answer can be found in Appendix A.