

DTFT, DFT, ZT, and FFT
463
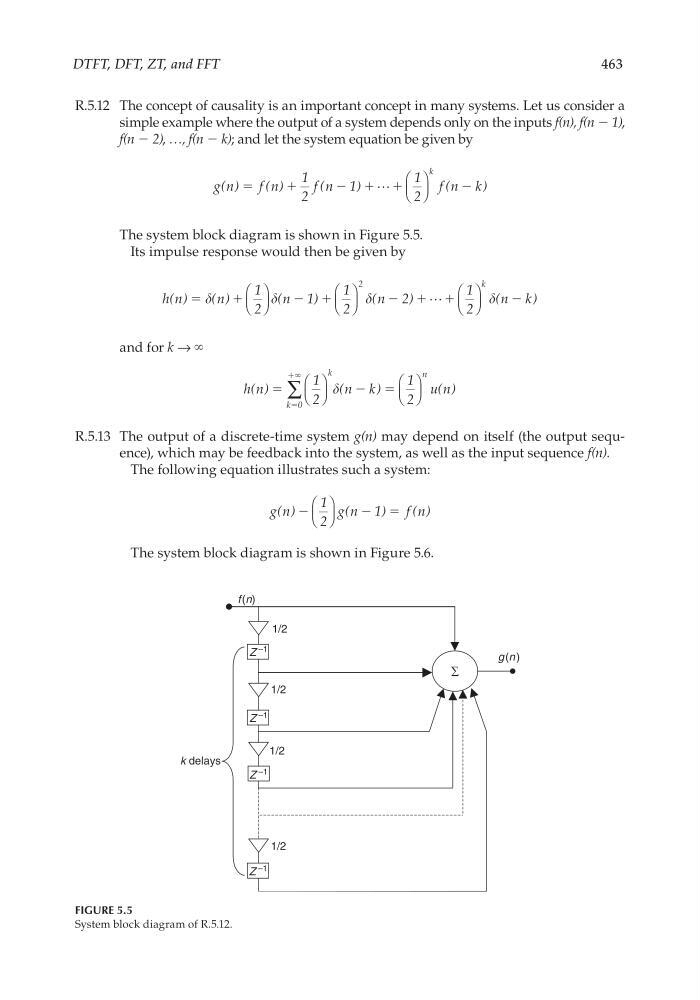
R.5.12 The concept of causality is an important concept in many systems. Let us consider a
simple example where the output of a system depends only on the inputs f(n), f(n − 1),
f(n − 2), …, f(n − k); and let the system equation be given by
g n
f n
f n
f n k
k
( )
( )
1
2
(
1)
1
2
(
)
ϭ
ϩ
Ϫ ϩ ϩ
Ϫ
The system block diagram is shown in Figure 5.5.
Its impulse response would then be given by
h n
n
n
n
n k
k
( )
( )
1
2
(
1)
1
2
(
2)
1
2
(
)
2
ϭ
ϩ
Ϫ ϩ
Ϫ ϩ ϩ
Ϫ
and for k → ∞
h n
n k
u n
k
k
n
( )
1
2
(
)
1
2
( )
0
ϭ
Ϫ ϭ
ϭ
ϩϱ
∑
R.5.13 The output of a discrete-time system g(n) may depend on itself (the output sequence), which may be feedback into the system, as well as the input sequence f(n).
The following equation illustrates such a system:
g n
g n
f n
( )
1
2
(
1)
( )
Ϫ
Ϫ ϭ
The system block diagram is shown in Figure 5.6.
FIGURE 5.5
System block diagram of R.5.12.
∑
Z
–1
k delays
g (n )
f (n)
Z
–1
Z
–1
Z
–1
1/2
1/2
1/2
1/2
CRC_47760_CH005.indd 463
CRC_47760_CH005.indd 463
7/23/2008 1:47:17 PM
7/23/2008 1:47:17 PM