

/**************** déclarations de service *****************/
#include "point3.h"
#include // pour sqrt et atan
#include
using namespace std ;
const float pi = 3.141592653 ; // valeur de pi
float angle (float, float) ; // fonction de service (non membre)
/*************** définition des fonctions membre **********/
point::point (float abs, float ord)
{ x = abs ; y = ord ;
}
void point::deplace (float dx, float dy)
{ x += dx ; y += dy ;
}
void point::homothetie (float hm)
{ x *= hm ; y *= hm ;
}
void point::rotation (float th)
{ float r = sqrt (x*x + y*y) ; // passage en
float t = angle (x, y) ; // coordonnées polaires
t += th ; // rotation th
x = r * cos (t) ; // retour en
y = r * sin (t) ; // coordonnées cartésiennes
}
float point::abscisse ()
{ return x ;
}
float point::ordonnee ()
{ return y ;
}
float point::rho ()
{ return sqrt (x*x + y*y) ;
}
float point::theta ()
{ return angle (x, y) ;
}
/********** définition des fonctions de service ***********/
/* fonction de calcul de l'angle correspondant aux coordonnées */
/* cartésiennes fournies en argument */
/* On choisit une détermination entre -pi et +pi (0 si x=0) */
float angle (float x, float y)
{ float a = x ? atan (y/x) : 0 ;
if (y<0) if (x>=0) return a + pi ;
else return a - pi ;
return a ;
}
139
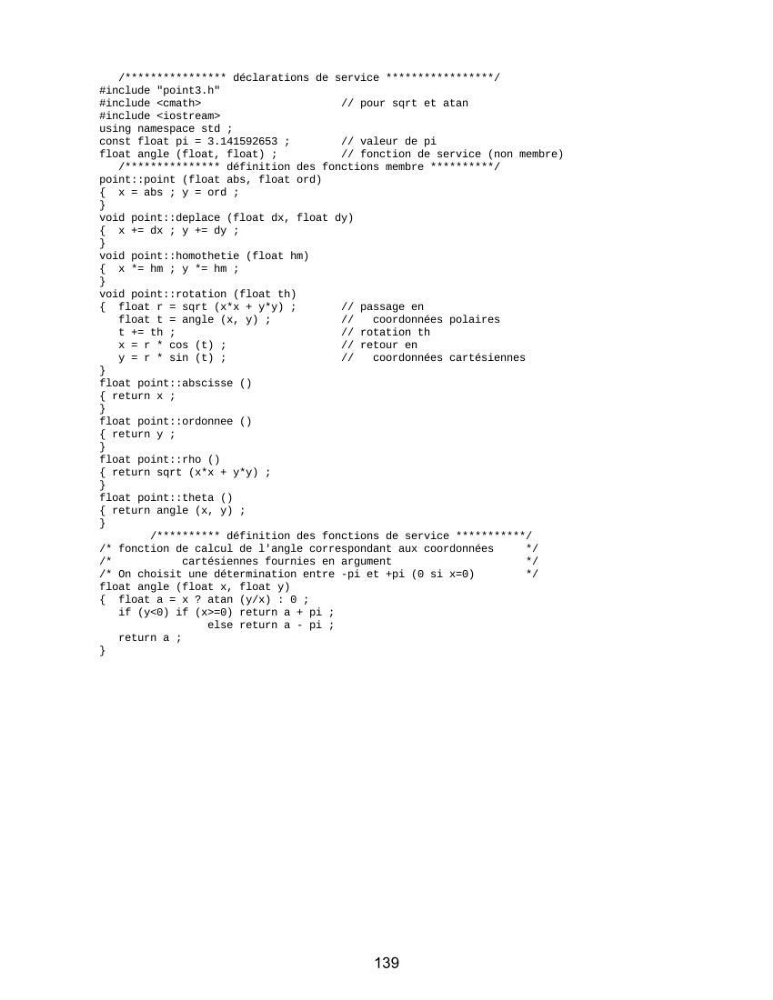
#include "point3.h"
#include
#include
using namespace std ;
const float pi = 3.141592653 ; // valeur de pi
float angle (float, float) ; // fonction de service (non membre)
/*************** définition des fonctions membre **********/
point::point (float abs, float ord)
{ x = abs ; y = ord ;
}
void point::deplace (float dx, float dy)
{ x += dx ; y += dy ;
}
void point::homothetie (float hm)
{ x *= hm ; y *= hm ;
}
void point::rotation (float th)
{ float r = sqrt (x*x + y*y) ; // passage en
float t = angle (x, y) ; // coordonnées polaires
t += th ; // rotation th
x = r * cos (t) ; // retour en
y = r * sin (t) ; // coordonnées cartésiennes
}
float point::abscisse ()
{ return x ;
}
float point::ordonnee ()
{ return y ;
}
float point::rho ()
{ return sqrt (x*x + y*y) ;
}
float point::theta ()
{ return angle (x, y) ;
}
/********** définition des fonctions de service ***********/
/* fonction de calcul de l'angle correspondant aux coordonnées */
/* cartésiennes fournies en argument */
/* On choisit une détermination entre -pi et +pi (0 si x=0) */
float angle (float x, float y)
{ float a = x ? atan (y/x) : 0 ;
if (y<0) if (x>=0) return a + pi ;
else return a - pi ;
return a ;
}
139