

20 Part Agents for Exchanging Modules of Manipulators
293
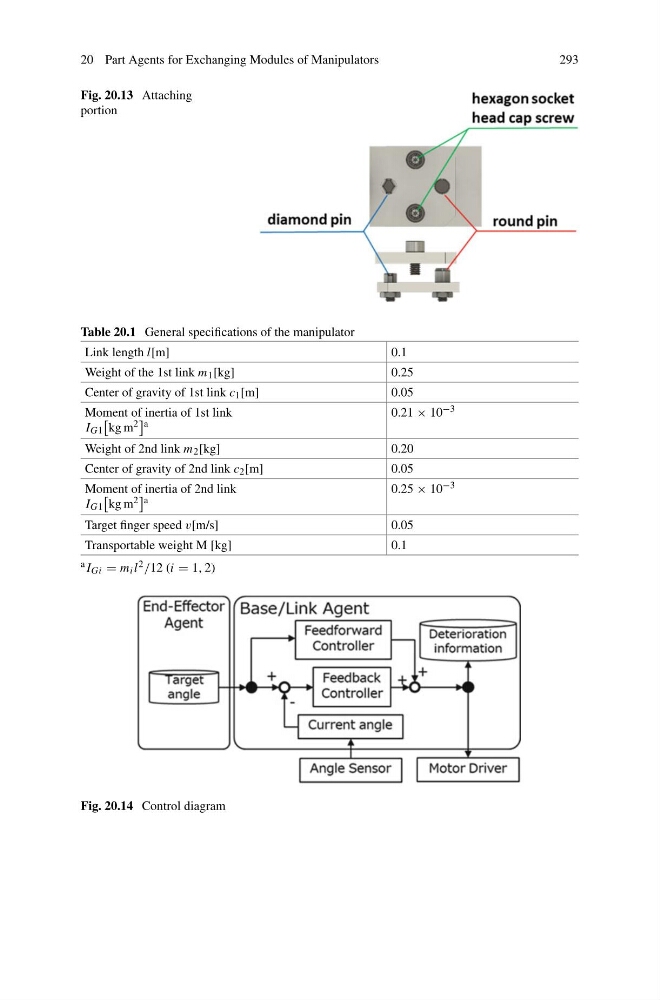
Fig. 20.13 Attaching
portion
Table 20.1 General specifications of the manipulator
Link length l[m]
0.1
Weight of the 1st link m 1 [kg]
0.25
Center of gravity of 1st link c 1 [m]
0.05
Moment of inertia of 1st link
I G1
kg m 2 a
0.21 × 10 −3
Weight of 2nd link m 2 [kg]
0.20
Center of gravity of 2nd link c 2 [m]
0.05
Moment of inertia of 2nd link
I G1
kg m 2 a
0.25 × 10 −3
Target finger speed v[m/s]
0.05
Transportable weight M [kg]
0.1
a I Gi = m i l 2 /12 (i = 1, 2)
Fig. 20.14 Control diagram