

6.5 Compression of Barrel-Shaped Bodies
65
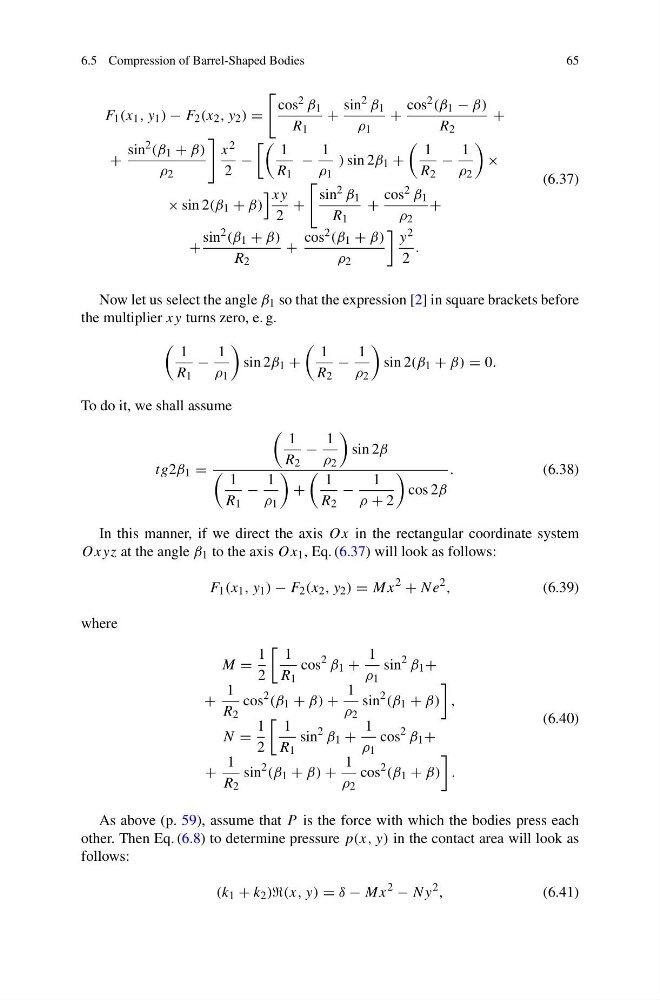
F 1 (x 1 , y 1 ) − F 2 (x 2 , y 2 ) =
cos 2 β 1
R 1
+
sin
2 β 1
ρ 1
+
cos 2 (β 1 − β)
R 2
+
+
sin
2 (β 1 + β)
ρ 2
x 2
2
−
1
R 1
−
1
ρ 1
) sin 2β 1 +
1
R 2
−
1
ρ 2
×
× sin 2(β 1 + β)
xy
2
+
sin
2 β 1
R 1
+
cos 2 β 1
ρ 2
+
+
sin
2 (β 1 + β)
R 2
+
cos 2 (β 1 + β)
ρ 2
y 2
2
.
(6.37)
Now let us select the angle β 1 so that the expression [2] in square brackets before
the multiplier xy turns zero, e. g.
1
R 1
−
1
ρ 1
sin 2β 1 +
1
R 2
−
1
ρ 2
sin 2(β 1 + β) = 0.
To do it, we shall assume
tg2β 1 =
1
R 2
−
1
ρ 2
sin 2β
1
R 1
−
1
ρ 1
+
1
R 2
−
1
ρ + 2
cos 2β
.
(6.38)
In this manner, if we direct the axis Ox in the rectangular coordinate system
Oxyz at the angle β 1 to the axis Ox 1 , Eq. (6.37) will look as follows:
F 1 (x 1 , y 1 ) − F 2 (x 2 , y 2 ) = Mx
2
+ Ne
2 ,
(6.39)
where
M =
1
2
1
R 1
cos
2 β 1 +
1
ρ 1
sin
2 β 1 +
+
1
R 2
cos
2 (β 1 + β) +
1
ρ 2
sin
2 (β 1 + β)
,
N =
1
2
1
R 1
sin
2 β 1 +
1
ρ 1
cos
2 β 1 +
+
1
R 2
sin
2 (β 1 + β) +
1
ρ 2
cos
2 (β 1 + β)
.
(6.40)
As above (p. 59), assume that P is the force with which the bodies press each
other. Then Eq. (6.8) to determine pressure p(x, y) in the contact area will look as
follows:
(k 1 + k 2 )(x, y) = δ − Mx
2
− Ny
2 ,
(6.41)