

166
13 Initial Concepts of Plasticity Theory
Dependencies (13.1) and (13.2) are used as a basis to adopt as follows.
Definition 1 A vector is an aggregate of three values a 1 , a 2 , a 3 related to this
coordinate system and transformed when switching to the other system using
formulas (13.1) and (13.2).
Similarly to the above, the following is adopted.
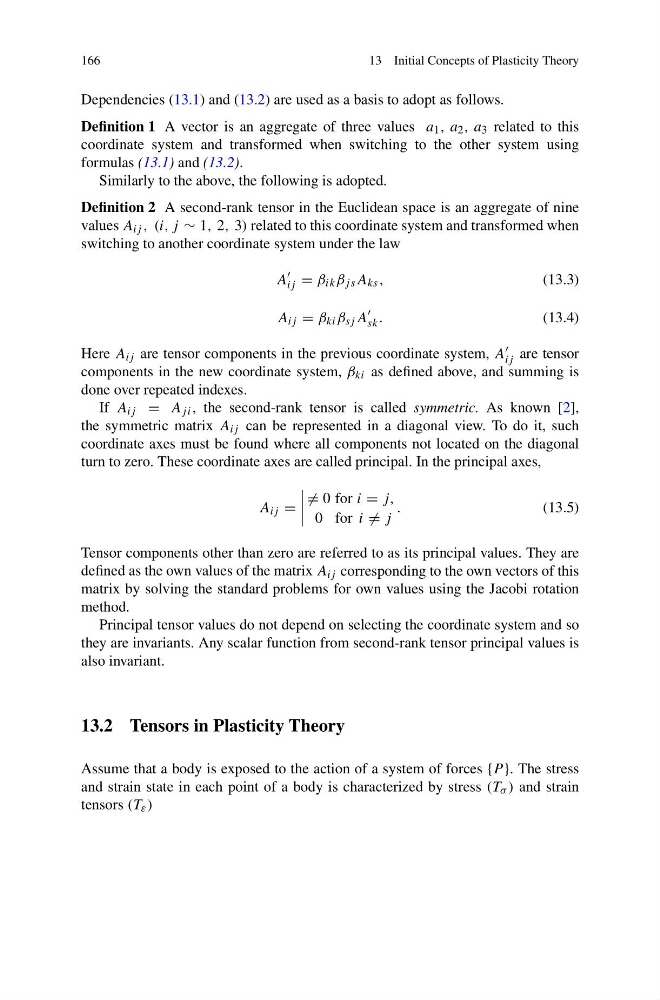
Definition 2 A second-rank tensor in the Euclidean space is an aggregate of nine
values A ij , (i, j ∼ 1, 2, 3) related to this coordinate system and transformed when
switching to another coordinate system under the law
A
ij = β ik β js A ks ,
(13.3)
A ij = β ki β sj A
sk .
(13.4)
Here A ij are tensor components in the previous coordinate system, A
ij are tensor
components in the new coordinate system, β ki as defined above, and summing is
done over repeated indexes.
If A ij = A ji , the second-rank tensor is called symmetric. As known [2],
the symmetric matrix A ij can be represented in a diagonal view. To do it, such
coordinate axes must be found where all components not located on the diagonal
turn to zero. These coordinate axes are called principal. In the principal axes,
A ij =
= 0 for i = j,
0 for i = j
.
(13.5)
Tensor components other than zero are referred to as its principal values. They are
defined as the own values of the matrix A ij corresponding to the own vectors of this
matrix by solving the standard problems for own values using the Jacobi rotation
method.
Principal tensor values do not depend on selecting the coordinate system and so
they are invariants. Any scalar function from second-rank tensor principal values is
also invariant.
13.2 Tensors in Plasticity Theory
Assume that a body is exposed to the action of a system of forces {P }. The stress
and strain state in each point of a body is characterized by stress (T σ ) and strain
tensors (T ε )