

20 Using Spectral Form of Mathematical Description …
293
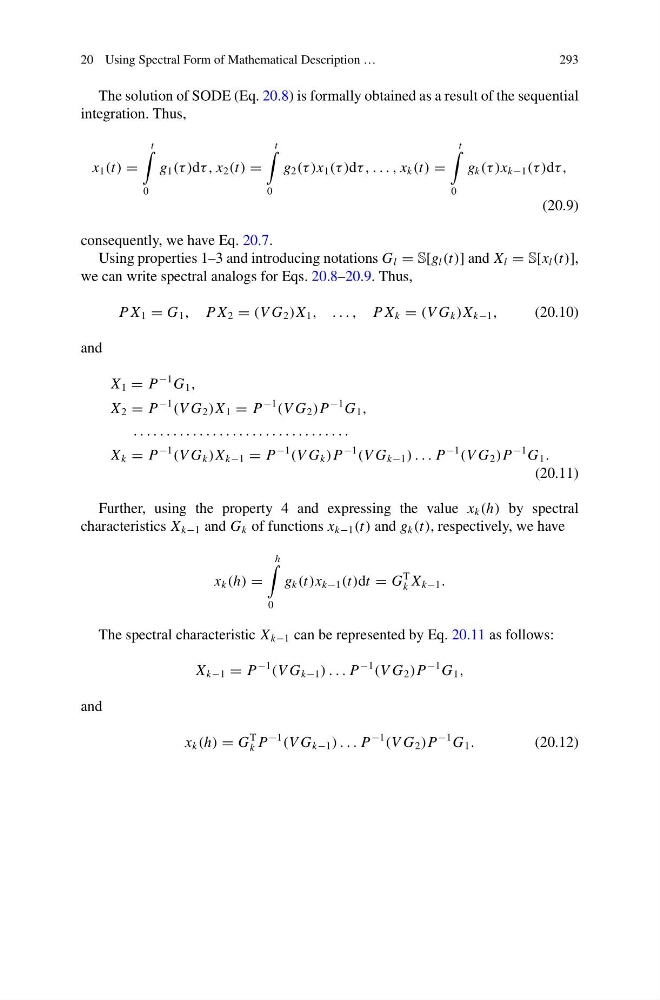
The solution of SODE (Eq. 20.8) is formally obtained as a result of the sequential
integration. Thus,
x 1 (t) =
t
0
g 1 (τ )dτ , x 2 (t) =
t
0
g 2 (τ )x 1 (τ )dτ , . . . , x k (t) =
t
0
g k (τ )x k−1 (τ )dτ ,
(20.9)
consequently, we have Eq. 20.7.
Using properties 1–3 and introducing notations G l = S[g l (t)] and X l = S[x l (t)],
we can write spectral analogs for Eqs. 20.8–20.9. Thus,
P X 1 = G 1 , P X 2 = (V G 2 )X 1 , . . . , P X k = (V G k )X k−1 ,
(20.10)
and
X 1 = P
−1 G 1 ,
X 2 = P
−1
(V G 2 )X 1 = P
−1
(V G 2 )P
−1 G 1 ,
. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .
X k = P
−1
(V G k )X k−1 = P
−1
(V G k )P
−1
(V G k−1 ) . . . P
−1
(V G 2 )P
−1 G 1 .
(20.11)
Further, using the property 4 and expressing the value x k (h) by spectral
characteristics X k−1 and G k of functions x k−1 (t) and g k (t), respectively, we have
x k (h) =
h
0
g k (t)x k−1 (t)dt = G
T
k X k−1 .
The spectral characteristic X k−1 can be represented by Eq. 20.11 as follows:
X k−1 = P
−1
(V G k−1 ) . . . P
−1
(V G 2 )P
−1 G 1 ,
and
x k (h) = G
T
k P
−1
(V G k−1 ) . . . P
−1
(V G 2 )P
−1 G 1 .
(20.12)