

16 Application of Multi-agent Optimization Methods …
221
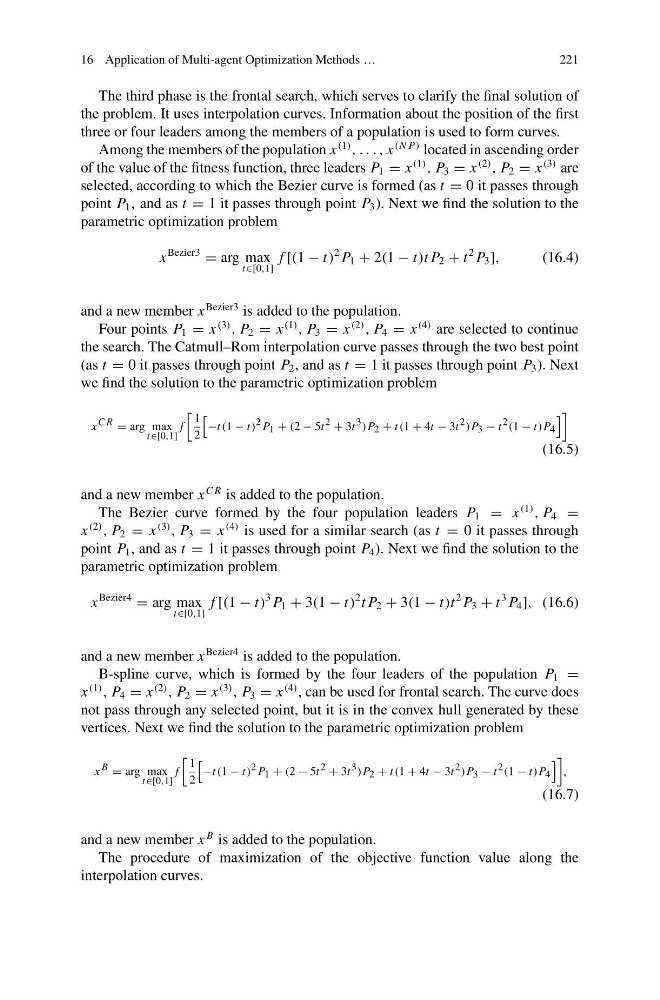
The third phase is the frontal search, which serves to clarify the final solution of
the problem. It uses interpolation curves. Information about the position of the first
three or four leaders among the members of a population is used to form curves.
Among the members of the population x
(1)
, . . . , x
(N P) located in ascending order
of the value of the fitness function, three leaders P 1 = x
(1)
, P 3 = x
(2)
, P 2 = x
(3) are
selected, according to which the Bezier curve is formed (as t = 0 it passes through
point P 1 , and as t = 1 it passes through point P 3 ). Next we find the solution to the
parametric optimization problem
x
Bezier3
= arg max
t∈[0,1]
f [(1 − t)
2 P 1 + 2(1 − t)t P 2 + t
2 P 3 ],
(16.4)
and a new member x
Bezier3 is added to the population.
Four points P 1 = x
(3)
, P 2 = x
(1)
, P 3 = x
(2)
, P 4 = x
(4) are selected to continue
the search. The Catmull–Rom interpolation curve passes through the two best point
(as t = 0 it passes through point P 2 , and as t = 1 it passes through point P 3 ). Next
we find the solution to the parametric optimization problem
x C R = arg max
t∈[0,1]
f
1
2
−t (1 − t) 2 P 1 + (2 − 5t 2 + 3t 3 )P 2 + t (1 + 4t − 3t 2 )P 3 − t 2 (1 − t)P 4
(16.5)
and a new member x
C R is added to the population.
The Bezier curve formed by the four population leaders P 1 = x
(1)
, P 4 =
x
(2)
, P 2 = x
(3)
, P 3 = x
(4) is used for a similar search (as t = 0 it passes through
point P 1 , and as t = 1 it passes through point P 4 ). Next we find the solution to the
parametric optimization problem
x
Bezier4
= arg max
t∈[0,1]
f [(1 − t)
3 P 1 + 3(1 − t)
2 t P 2 + 3(1 − t)t
2 P 3 + t
3 P 4 ], (16.6)
and a new member x
Bezier4 is added to the population.
B-spline curve, which is formed by the four leaders of the population P 1 =
x
(1)
, P 4 = x
(2)
, P 2 = x
(3)
, P 3 = x
(4) , can be used for frontal search. The curve does
not pass through any selected point, but it is in the convex hull generated by these
vertices. Next we find the solution to the parametric optimization problem
x B = arg max
t∈[0,1]
f
1
2
−t (1 − t) 2 P 1 + (2 − 5t 2 + 3t 3 )P 2 + t (1 + 4t − 3t 2 )P 3 − t 2 (1 − t)P 4
,
(16.7)
and a new member x
B is added to the population.
The procedure of maximization of the objective function value along the
interpolation curves.