

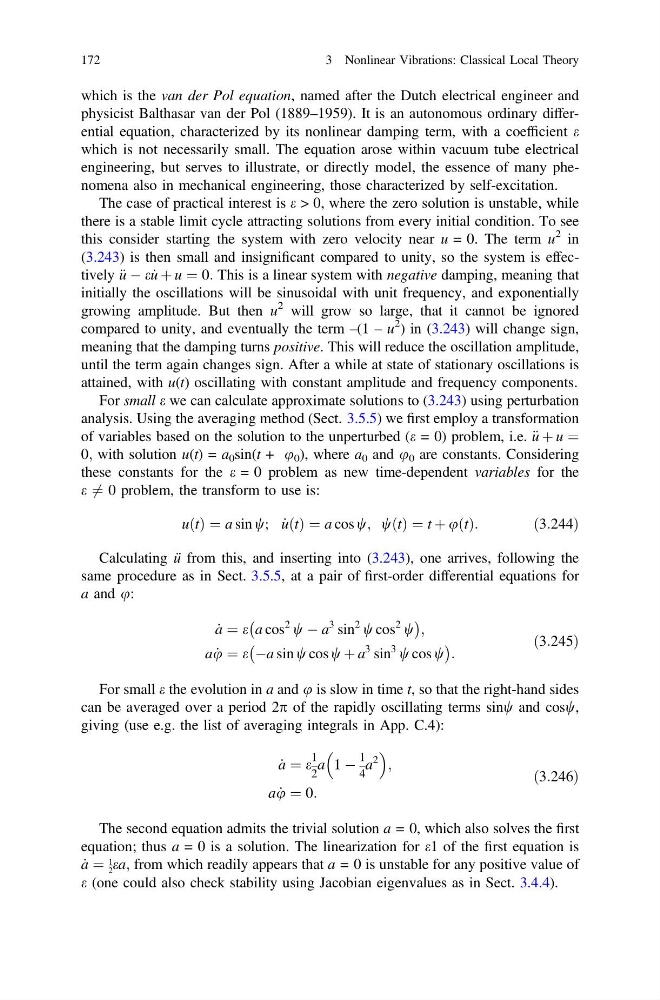
which is the van der Pol equation, named after the Dutch electrical engineer and
physicist Balthasar van der Pol (1889–1959). It is an autonomous ordinary differential equation, characterized by its nonlinear damping term, with a coefficient e
which is not necessarily small. The equation arose within vacuum tube electrical
engineering, but serves to illustrate, or directly model, the essence of many phenomena also in mechanical engineering, those characterized by self-excitation.
The case of practical interest is e > 0, where the zero solution is unstable, while
there is a stable limit cycle attracting solutions from every initial condition. To see
this consider starting the system with zero velocity near u = 0. The term u
2 in
(3.243) is then small and insignificant compared to unity, so the system is effectively € u À e _
u þ u ¼ 0: This is a linear system with negative damping, meaning that
initially the oscillations will be sinusoidal with unit frequency, and exponentially
growing amplitude. But then u
2 will grow so large, that it cannot be ignored
compared to unity, and eventually the term –(1 – u
2 ) in (3.243) will change sign,
meaning that the damping turns positive. This will reduce the oscillation amplitude,
until the term again changes sign. After a while at state of stationary oscillations is
attained, with u(t) oscillating with constant amplitude and frequency components.
For small e we can calculate approximate solutions to (3.243) using perturbation
analysis. Using the averaging method (Sect. 3.5.5) we first employ a transformation
of variables based on the solution to the unperturbed (e = 0) problem, i.e. € u þ u ¼
0; with solution u(t) = a 0 sin(t + u 0 ), where a 0 and u 0 are constants. Considering
these constants for the e = 0 problem as new time-dependent variables for the
e 6 ¼ 0 problem, the transform to use is:
uðtÞ ¼ a sin w; _
uðtÞ ¼ a cos w; wðtÞ ¼ t þ uðtÞ:
ð3:244Þ
Calculating ü from this, and inserting into (3.243), one arrives, following the
same procedure as in Sect. 3.5.5, at a pair of first-order differential equations for
a and u:
_
a ¼ e a cos
2 w À a
3 sin
2 w cos
2 w
À
Á ;
a _
u ¼ e Àa sin w cos w þ a
3 sin
3 w cos w
À
Á :
ð3:245Þ
For small e the evolution in a and u is slow in time t, so that the right-hand sides
can be averaged over a period 2p of the rapidly oscillating terms sinw and cosw,
giving (use e.g. the list of averaging integrals in App. C.4):
_
a ¼ e
1
2
a 1 À
1
4
a
2
;
a _
u ¼ 0:
ð3:246Þ
The second equation admits the trivial solution a = 0, which also solves the first
equation; thus a = 0 is a solution. The linearization for e1 of the first equation is
_
a ¼
1
2 ea; from which readily appears that a = 0 is unstable for any positive value of
e (one could also check stability using Jacobian eigenvalues as in Sect. 3.4.4).
172
3 Nonlinear Vibrations: Classical Local Theory