

5.8 Numerical Algorithms
97
(k)
q (k+1)
< .
(5.109)
5.8.4 Riks-Wempner Method
The Riks-Wempner algorithm is an arc-length control method, used for solving nonlinear equilibrium equations, especially for buckling analysis. The algorithm can be
found in many books e.g. [8, 15]. The strategies of searching the equilibrium point
is critical important. Two approaches for determine the searching direction, namely
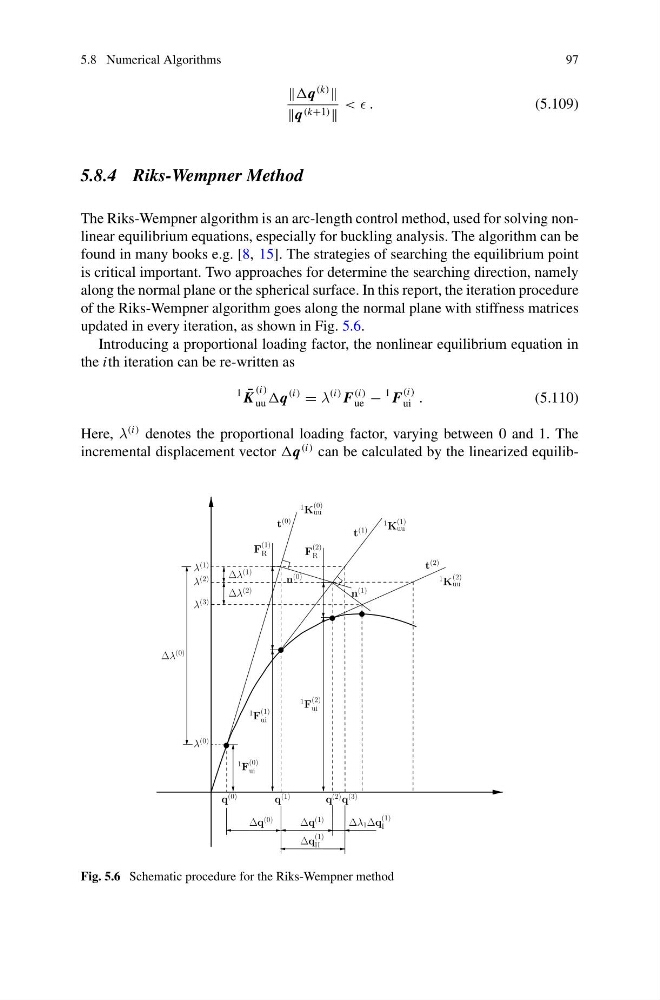
along the normal plane or the spherical surface. In this report, the iteration procedure
of the Riks-Wempner algorithm goes along the normal plane with stiffness matrices
updated in every iteration, as shown in Fig. 5.6.
Introducing a proportional loading factor, the nonlinear equilibrium equation in
the ith iteration can be re-written as
1 ¯
K
(i)
uu
(i)
= λ
(i) F
(i)
ue −
1 F
(i)
ui .
(5.110)
Here, λ
(i) denotes the proportional loading factor, varying between 0 and 1. The
incremental displacement vector
(i) can be calculated by the linearized equilibq
(3)
q
(0)
q
(1)
q
(2)
Δq
(0)
Δq
(1)
Δλ 1 Δq
(1)
I
Δq
(1)
II
1 K
(0)
uu
1 K
(1)
uu
1 K
(2)
uu
1 F
(0)
ui
1 F
(2)
ui
1 F
(1)
ui
t
(2)
t
(1)
n
(1)
t
(0)
n
(0)
F
(2)
R
F
(1)
R
Δλ
(1)
Δλ
(2)
λ
(0)
λ
(3)
λ
(2)
λ
(1)
Δλ
(0)
Fig. 5.6 Schematic procedure for the Riks-Wempner method