

2.5 Coordinate Transformation
35
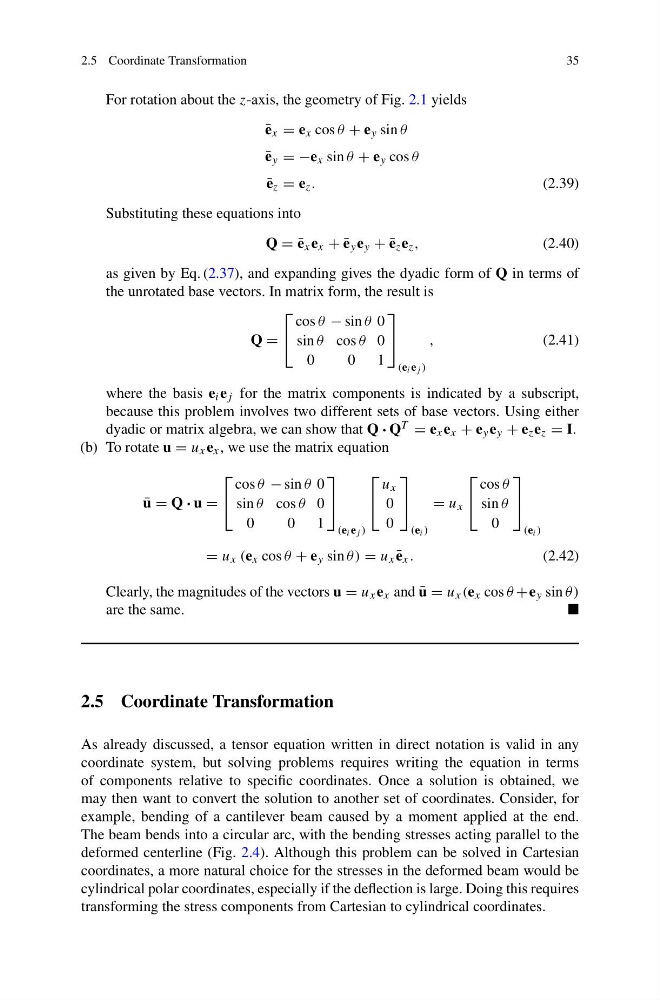
For rotation about the z-axis, the geometry of Fig. 2.1 yields
¯
e x = e x cos θ + e y sin θ
¯
e y = −e x sin θ + e y cos θ
¯
e z = e z .
(2.39)
Substituting these equations into
Q = ¯
e x e x + ¯
e y e y + ¯
e z e z ,
(2.40)
as given by Eq. (2.37), and expanding gives the dyadic form of Q in terms of
the unrotated base vectors. In matrix form, the result is
Q =
⎡
⎣
cos θ − sin θ 0
sin θ cos θ 0
0
0 1
⎤
⎦
(e i e j )
,
(2.41)
where the basis e i e j for the matrix components is indicated by a subscript,
because this problem involves two different sets of base vectors. Using either
dyadic or matrix algebra, we can show that Q · Q T = e x e x + e y e y + e z e z = I.
(b) To rotate u = u x e x , we use the matrix equation
¯
u = Q · u =
⎡
⎣
cos θ − sin θ 0
sin θ cos θ 0
0
0 1
⎤
⎦
(e i e j )
⎡
⎣
u x
0
0
⎤
⎦
(e i )
= u x
⎡
⎣
cos θ
sin θ
0
⎤
⎦
(e i )
= u x (e x cos θ + e y sin θ) = u x ¯
e x .
(2.42)
Clearly, the magnitudes of the vectors u = u x e x and ¯
u = u x (e x cos θ +e y sin θ)
are the same.
2.5 Coordinate Transformation
As already discussed, a tensor equation written in direct notation is valid in any
coordinate system, but solving problems requires writing the equation in terms
of components relative to specific coordinates. Once a solution is obtained, we
may then want to convert the solution to another set of coordinates. Consider, for
example, bending of a cantilever beam caused by a moment applied at the end.
The beam bends into a circular arc, with the bending stresses acting parallel to the
deformed centerline (Fig. 2.4). Although this problem can be solved in Cartesian
coordinates, a more natural choice for the stresses in the deformed beam would be
cylindrical polar coordinates, especially if the deflection is large. Doing this requires
transforming the stress components from Cartesian to cylindrical coordinates.