

138
3 Continuum Mechanics and Nonlinear Elasticity
W =
n
i=0
n
j =0
n
k=0
c ij k (I 1 − 3)
i (I 2 − 3)
j (I 3 − 1)
k .
(3.221)
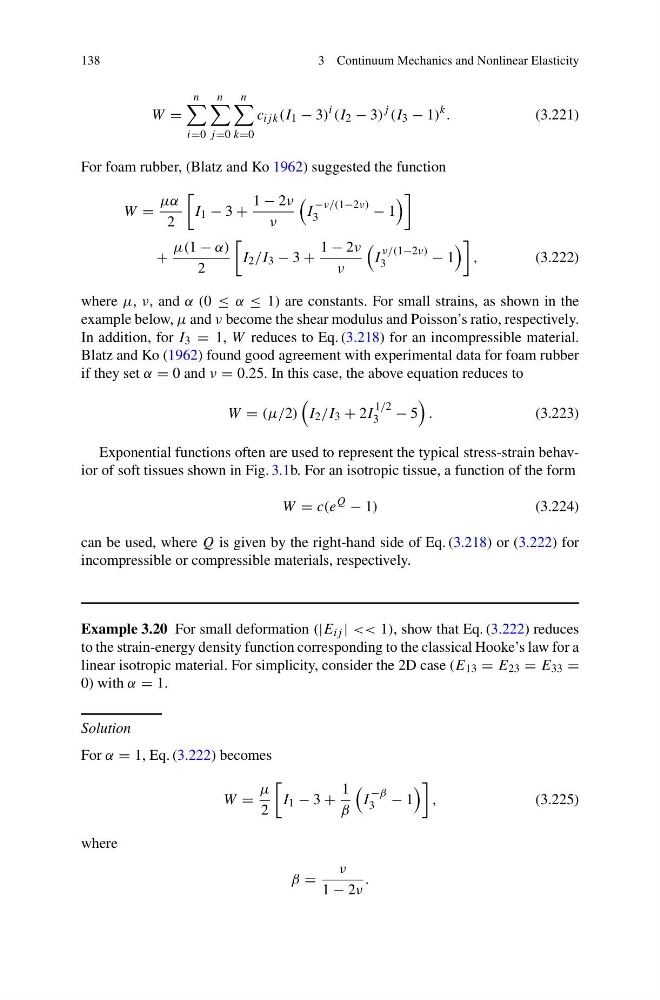
For foam rubber, (Blatz and Ko 1962) suggested the function
W =
μα
2
I 1 − 3 +
1 − 2ν
ν
I
−ν/(1−2ν)
3
− 1
+
μ(1 − α)
2
I 2 /I 3 − 3 +
1 − 2ν
ν
I
ν/(1−2ν)
3
− 1
,
(3.222)
where μ, ν, and α (0 ≤ α ≤ 1) are constants. For small strains, as shown in the
example below, μ and ν become the shear modulus and Poisson’s ratio, respectively.
In addition, for I 3 = 1, W reduces to Eq. (3.218) for an incompressible material.
Blatz and Ko (1962) found good agreement with experimental data for foam rubber
if they set α = 0 and ν = 0.25. In this case, the above equation reduces to
W = (μ/2)
I 2 /I 3 + 2I
1/2
3 − 5
.
(3.223)
Exponential functions often are used to represent the typical stress-strain behavior of soft tissues shown in Fig. 3.1b. For an isotropic tissue, a function of the form
W = c(e
Q
− 1)
(3.224)
can be used, where Q is given by the right-hand side of Eq. (3.218) or (3.222) for
incompressible or compressible materials, respectively.
Example 3.20 For small deformation (|E ij | << 1), show that Eq. (3.222) reduces
to the strain-energy density function corresponding to the classical Hooke’s law for a
linear isotropic material. For simplicity, consider the 2D case (E 13 = E 23 = E 33 =
0) with α = 1.
Solution
For α = 1, Eq. (3.222) becomes
W =
μ
2
I 1 − 3 +
1
β
I
−β
3 − 1
,
(3.225)
where
β =
ν
1 − 2ν
.