

120
3 Continuum Mechanics and Nonlinear Elasticity
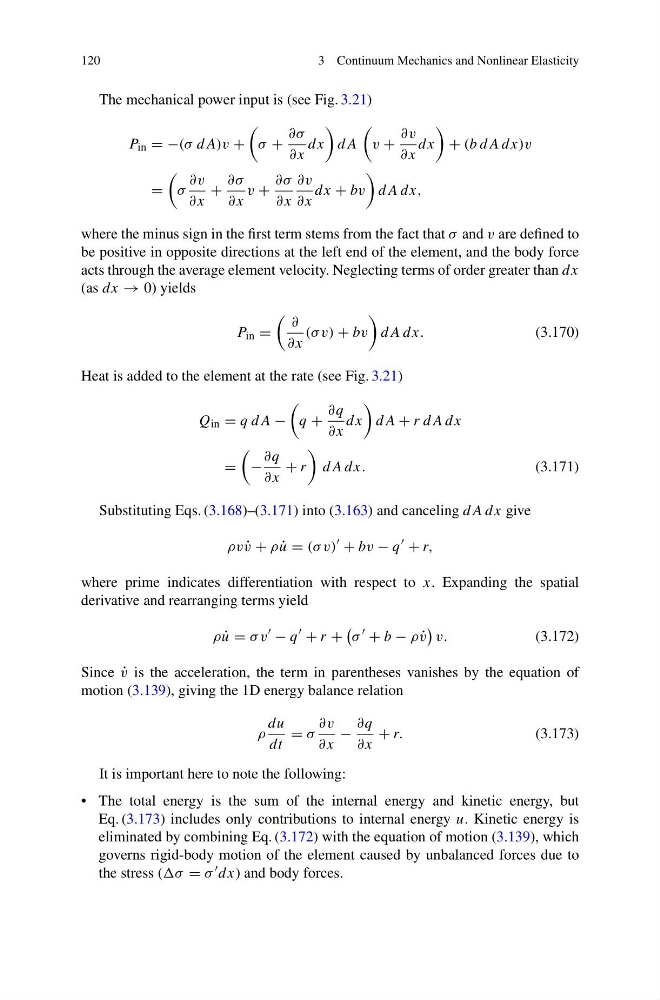
The mechanical power input is (see Fig. 3.21)
P in = −(σ dA)v +
σ +
∂σ
∂x
dx
dA
v +
∂v
∂x
dx
+ (b dA dx)v
=
σ
∂v
∂x
+
∂σ
∂x
v +
∂σ
∂x
∂v
∂x
dx + bv
dA dx,
where the minus sign in the first term stems from the fact that σ and v are defined to
be positive in opposite directions at the left end of the element, and the body force
acts through the average element velocity. Neglecting terms of order greater than dx
(as dx → 0) yields
P in =
∂
∂x
(σ v) + bv
dA dx.
(3.170)
Heat is added to the element at the rate (see Fig. 3.21)
Q in = q dA −
q +
∂q
∂x
dx
dA + r dA dx
=
−
∂q
∂x
+ r
dA dx.
(3.171)
Substituting Eqs. (3.168)–(3.171) into (3.163) and canceling dA dx give
ρv ˙
v + ρ ˙
u = (σ v)
+ bv − q
+ r,
where prime indicates differentiation with respect to x. Expanding the spatial
derivative and rearranging terms yield
ρ ˙
u = σ v
− q
+ r +
σ
+ b − ρ ˙
v
v.
(3.172)
Since ˙
v is the acceleration, the term in parentheses vanishes by the equation of
motion (3.139), giving the 1D energy balance relation
ρ
du
dt
= σ
∂v
∂x
−
∂q
∂x
+ r.
(3.173)
It is important here to note the following:
• The total energy is the sum of the internal energy and kinetic energy, but
Eq. (3.173) includes only contributions to internal energy u. Kinetic energy is
eliminated by combining Eq. (3.172) with the equation of motion (3.139), which
governs rigid-body motion of the element caused by unbalanced forces due to
the stress (σ = σ dx) and body forces.