

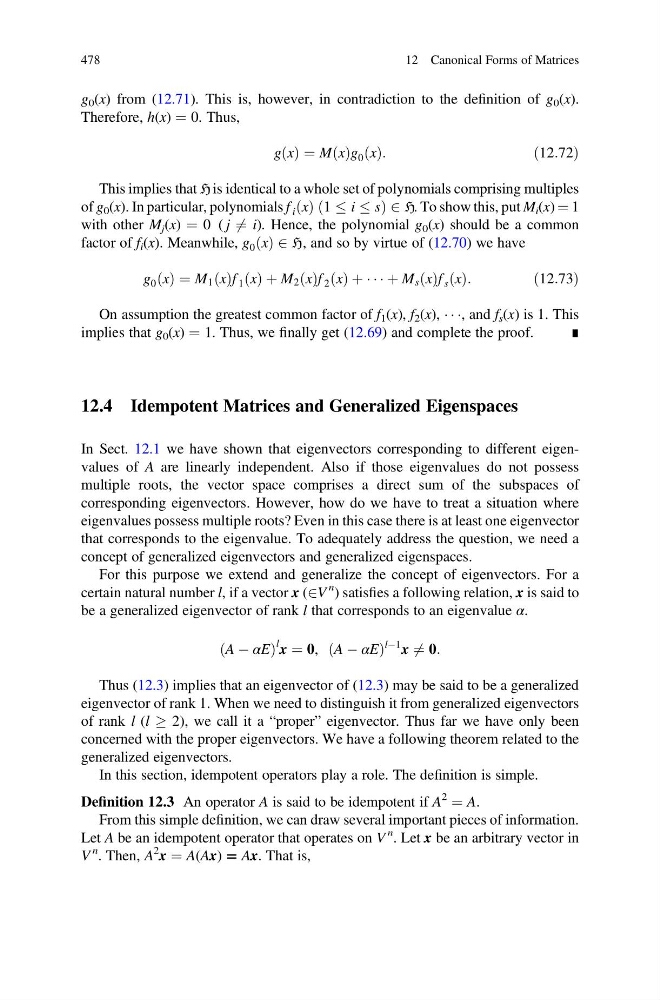
g 0 (x) from (12.71). This is, however, in contradiction to the definition of g 0 (x).
Therefore, h(x) ¼ 0. Thus,
g x
ð Þ ¼ M x
ð Þg 0 x
ð Þ:
ð12:72Þ
This implies that H is identical to a whole set of polynomials comprising multiples
of g 0 (x). In particular, polynomials f i x
ð Þ 1 i s
ð
Þ2H. To show this, put M i (x) ¼ 1
with other M j (x) ¼ 0 ( j 6 ¼ i). Hence, the polynomial g 0 (x) should be a common
factor of f i (x). Meanwhile, g 0 x
ð Þ 2 H, and so by virtue of (12.70) we have
g 0 x
ð Þ ¼ M 1 x
ð Þf 1 x
ð Þ þ M 2 x
ð Þf 2 x
ð Þ þ Á Á Á þ M s x
ð Þf s x
ð Þ:
ð12:73Þ
On assumption the greatest common factor of f 1 (x), f 2 (x), Á Á Á, and f s (x) is 1. This
implies that g 0 (x) ¼ 1. Thus, we finally get (12.69) and complete the proof.
∎
12.4 Idempotent Matrices and Generalized Eigenspaces
In Sect. 12.1 we have shown that eigenvectors corresponding to different eigenvalues of A are linearly independent. Also if those eigenvalues do not possess
multiple roots, the vector space comprises a direct sum of the subspaces of
corresponding eigenvectors. However, how do we have to treat a situation where
eigenvalues possess multiple roots? Even in this case there is at least one eigenvector
that corresponds to the eigenvalue. To adequately address the question, we need a
concept of generalized eigenvectors and generalized eigenspaces.
For this purpose we extend and generalize the concept of eigenvectors. For a
certain natural number l, if a vector x (2V
n ) satisfies a following relation, x is said to
be a generalized eigenvector of rank l that corresponds to an eigenvalue α.
A À αE
ð
Þ
l x ¼ 0, A À αE
ð
Þ
lÀ1 x 6 ¼ 0:
Thus (12.3) implies that an eigenvector of (12.3) may be said to be a generalized
eigenvector of rank 1. When we need to distinguish it from generalized eigenvectors
of rank l (l ! 2), we call it a “proper” eigenvector. Thus far we have only been
concerned with the proper eigenvectors. We have a following theorem related to the
generalized eigenvectors.
In this section, idempotent operators play a role. The definition is simple.
Definition 12.3 An operator A is said to be idempotent if A
2
¼ A.
From this simple definition, we can draw several important pieces of information.
Let A be an idempotent operator that operates on V
n . Let x be an arbitrary vector in
V
n . Then, A
2 x ¼ A(Ax) = Ax. That is,
478
12 Canonical Forms of Matrices