

314
A. Sedlackova et al.
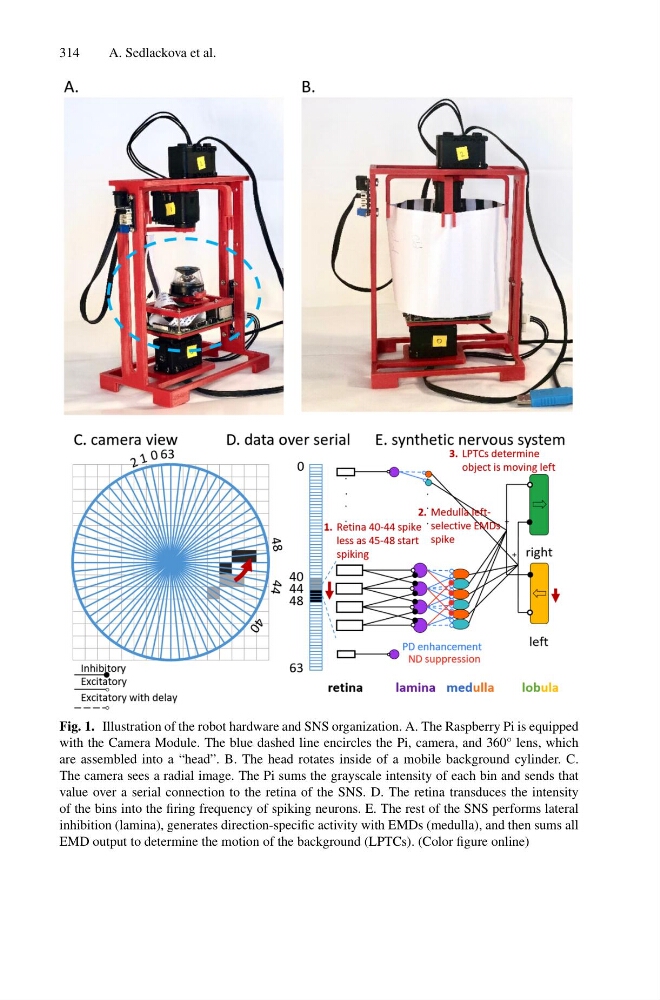
Fig. 1. Illustration of the robot hardware and SNS organization. A. The Raspberry Pi is equipped
with the Camera Module. The blue dashed line encircles the Pi, camera, and 360° lens, which
are assembled into a “head”. B. The head rotates inside of a mobile background cylinder. C.
The camera sees a radial image. The Pi sums the grayscale intensity of each bin and sends that
value over a serial connection to the retina of the SNS. D. The retina transduces the intensity
of the bins into the firing frequency of spiking neurons. E. The rest of the SNS performs lateral
inhibition (lamina), generates direction-specific activity with EMDs (medulla), and then sums all
EMD output to determine the motion of the background (LPTCs). (Color figure online)