

6.4 Matrix Formulation of Scattering for the jth Bilayer …
117
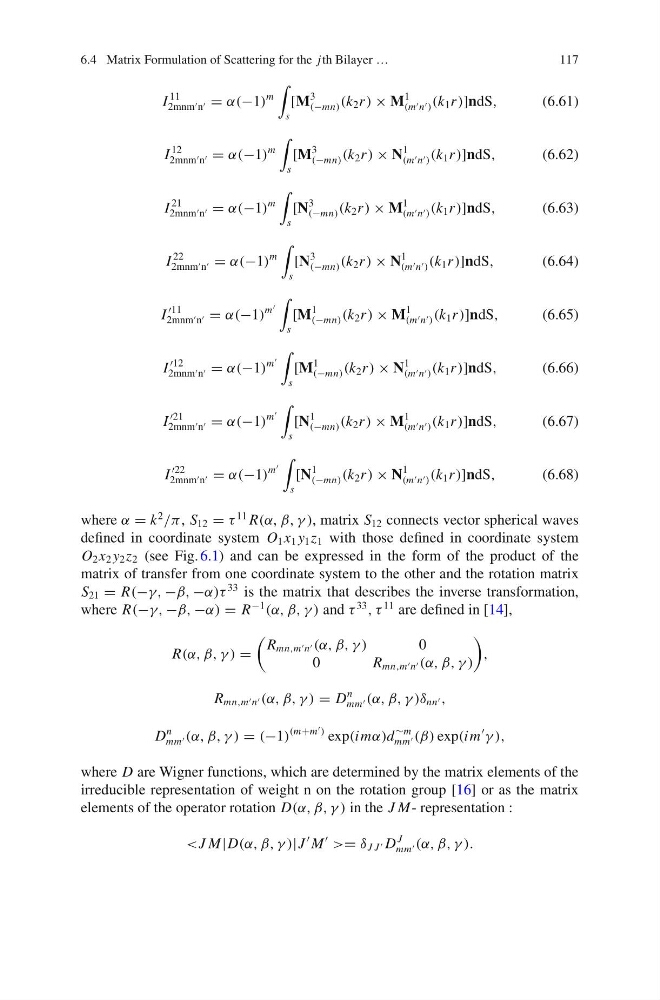
I
11
2mnm n = α(−1)
m
s
[M
3
(−mn) (k 2 r ) × M
1
(m n ) (k 1 r )]ndS,
(6.61)
I
12
2mnm n = α(−1)
m
s
[M
3
(−mn) (k 2 r ) × N
1
(m n ) (k 1 r )]ndS,
(6.62)
I
21
2mnm n = α(−1)
m
s
[N
3
(−mn) (k 2 r ) × M
1
(m n ) (k 1 r )]ndS,
(6.63)
I
22
2mnm n = α(−1)
m
s
[N
3
(−mn) (k 2 r ) × N
1
(m n ) (k 1 r )]ndS,
(6.64)
I
11
2mnm n = α(−1)
m
s
[M
1
(−mn) (k 2 r ) × M
1
(m n ) (k 1 r )]ndS,
(6.65)
I
12
2mnm n = α(−1)
m
s
[M
1
(−mn) (k 2 r ) × N
1
(m n ) (k 1 r )]ndS,
(6.66)
I
21
2mnm n = α(−1)
m
s
[N
1
(−mn) (k 2 r ) × M
1
(m n ) (k 1 r )]ndS,
(6.67)
I
22
2mnm n = α(−1)
m
s
[N
1
(−mn) (k 2 r ) × N
1
(m n ) (k 1 r )]ndS,
(6.68)
where α = k
2
/π , S 12 = τ
11 R(α, β, γ ), matrix S 12 connects vector spherical waves
defined in coordinate system O 1 x 1 y 1 z 1 with those defined in coordinate system
O 2 x 2 y 2 z 2 (see Fig. 6.1) and can be expressed in the form of the product of the
matrix of transfer from one coordinate system to the other and the rotation matrix
S 21 = R(−γ, −β, −α)τ
33 is the matrix that describes the inverse transformation,
where R(−γ, −β, −α) = R
−1
(α, β, γ ) and τ
33
, τ
11 are defined in [14],
R(α, β, γ ) =
R mn,m n (α, β, γ )
0
0
R mn,m n (α, β, γ )
,
R mn,m n (α, β, γ ) = D
n
mm (α, β, γ )δ nn ,
D
n
mm (α, β, γ ) = (−1)
(m+m
) exp(imα)d
∼m
mm (β) exp(im
γ ),
where D are Wigner functions, which are determined by the matrix elements of the
irreducible representation of weight n on the rotation group [16] or as the matrix
elements of the operator rotation D(α, β, γ ) in the J M- representation :
>= δ J J D
J
mm (α, β, γ ).