

Improvement of fine-grained and cohesive soils 111
transformed into circular columns of equal cross-sectional area in relevant
design calculations.
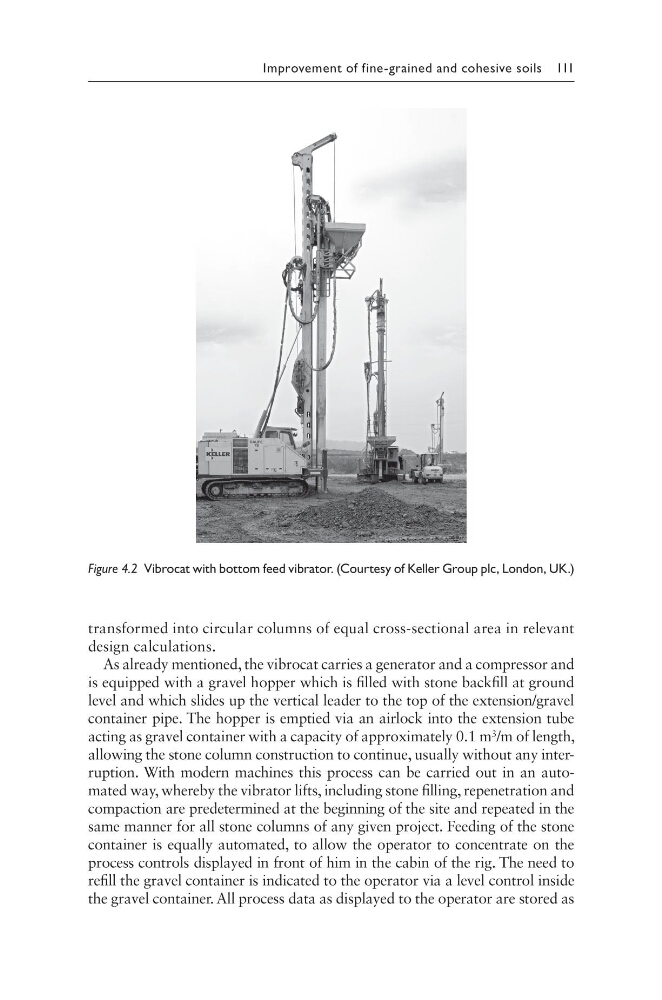
As already mentioned, the vibrocat carries a generator and a compressor and
is equipped with a gravel hopper which is filled with stone backfill at ground
level and which slides up the vertical leader to the top of the extension/gravel
container pipe. The hopper is emptied via an airlock into the extension tube
acting as gravel container with a capacity of approximately 0.1 m 3 /m of length,
allowing the stone column construction to continue, usually without any interruption. With modern machines this process can be carried out in an automated way, whereby the vibrator lifts, including stone filling, repenetration and
compaction are predetermined at the beginning of the site and repeated in the
same manner for all stone columns of any given project. Feeding of the stone
container is equally automated, to allow the operator to concentrate on the
process controls displayed in front of him in the cabin of the rig. The need to
refill the gravel container is indicated to the operator via a level control inside
the gravel container. All process data as displayed to the operator are stored as
Figure 4.2 Vibrocat with bottom feed vibrator. (Courtesy of Keller Group plc, London, UK.)