

32
STRUCTURE-ENVIRONMENTAL FORCE INTERACTIONS
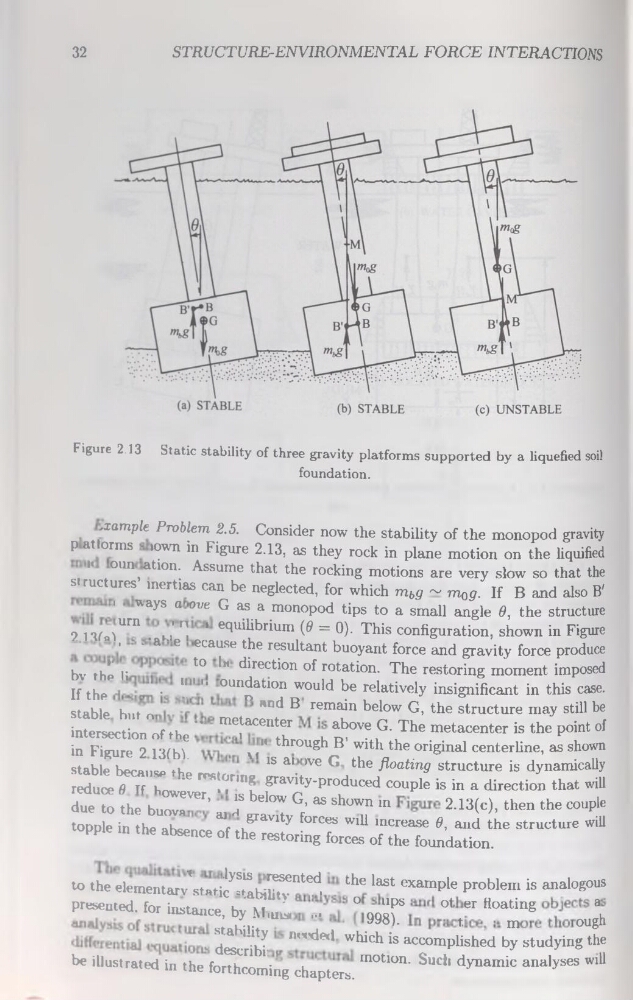
Figure 2.13 Static stability of three gravity platforms supportée! by a liquefied soil
foundation.
.xample Problem 2.5. Consider now the stability of the monopod gravity
p atlorms town in Figure 2.13, as they rock in plane motion on the liquified
i< oun, ation. Assume that the rocking motions are very slow so that the
st ructures mertias can be neglected, for which mbg ~ mog. If B and also B'
• v,ays a ove G as a monopod tips to a small angle 0, the structure
9 l'tfa'iUrn . m' \ * equilibrium (0 = 0). This configuration, shown in Figure
> . a e ecause the résultant buoyant force and gravity force produce
bv rht r
t0 * J direction of rotation. The restoring moment imposed
If the
• ' Z ''' Oun^atlon would be relatively insignifiant in this case,
stable but n
ar'd B remain below G, the structure may still be
intersection of th " meJ'acenter
aBove G. The metacenter is the point of
in Figure 2 13fb^
\i" thæughB’ with the original centerline, as shown
stable becausp the r^tormg Xatï^ G ,the ,fl°atin9 structure is dynamically
reduce 8 Tf h™
» r t Sravity-produced couple is in a direction that will
due to the buZ^’ 1S bel°W G’ “ ShüWn ln
2.13(c), then the couple
topple in the absc
ær ,gravlty forces Wlli ‘ncrease S, and the structure will
topple m the absence of the restoring forces of the foundation.
to the elemenUrv'staHé^ly^1116'1,
th' last examPle problem is analogous
ptesented. for instance, by M,„l...
°99^
°‘t" "““"S
“h
S",wted " -«bT«^
be illustrated in the forthcéttong chapters. mOtl°n' S“C1‘ dynamic analySeS W‘U