

A MONOPOD GRAVITY PLATFORM
237
It follows that the K matrix from équation (9.47) is given by
3.44 x 10⁹ N/m -0.0641 x 10¹² N
-0.0638 x 1Û12 N 2.99 x 10¹² N-m
(9.52)
Because of roundoff errors and possible variations in the experimental values of
the soil foundation constants, the last matrix is not symmetric to three significant figures.
Following équations (8.62)-(8.64), there is a corresponding modal vector
for each frequency un, computed from
(K-u>2 „M)£„ = 0,
n = l,2
(9.53)
in which the component form of the nonnormalized modal vector is
î„ = [1
G„r
(9.54)
The last two équations, when combined and written in component form, are
fcn-cu2m
kï2
|
1
0
, >
^21
^22 —
J . Gn .
®
The first of these two équations is solved for £2n to give
=
O»)
«12
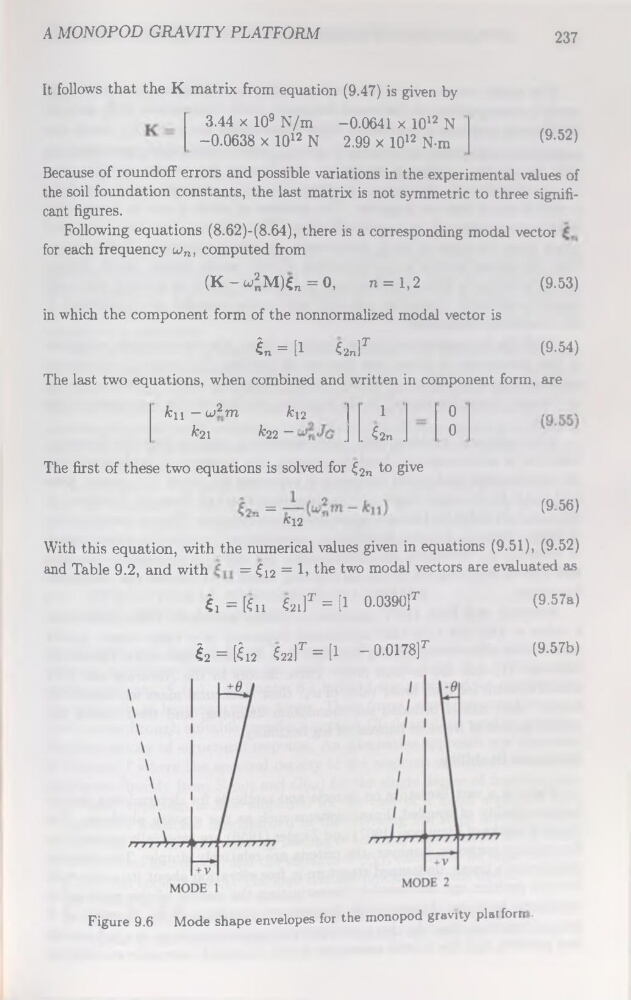
With this équation, with the numerical values given in équations (9.51), (9.52)
and Table 9.2, and with
= C12 = h the tw0 modal vectors are evaluated as
!,=!«„ «21]T = [1 0.0390]r
(9.57a)
ê2 = (êl2 «22]T=|1 -0.0178]r
(9.57b)
Figure 9.6 Mode shape envelopes for the monopod gravity plaiforrr