

224
APPLICATIONS OF MULTI-DEGREE OF FREEDOM ANALYSIS
9.1 A FIXED LEG PLATFORM: TIME DOMAIN RESPONSES
Mathematical Model
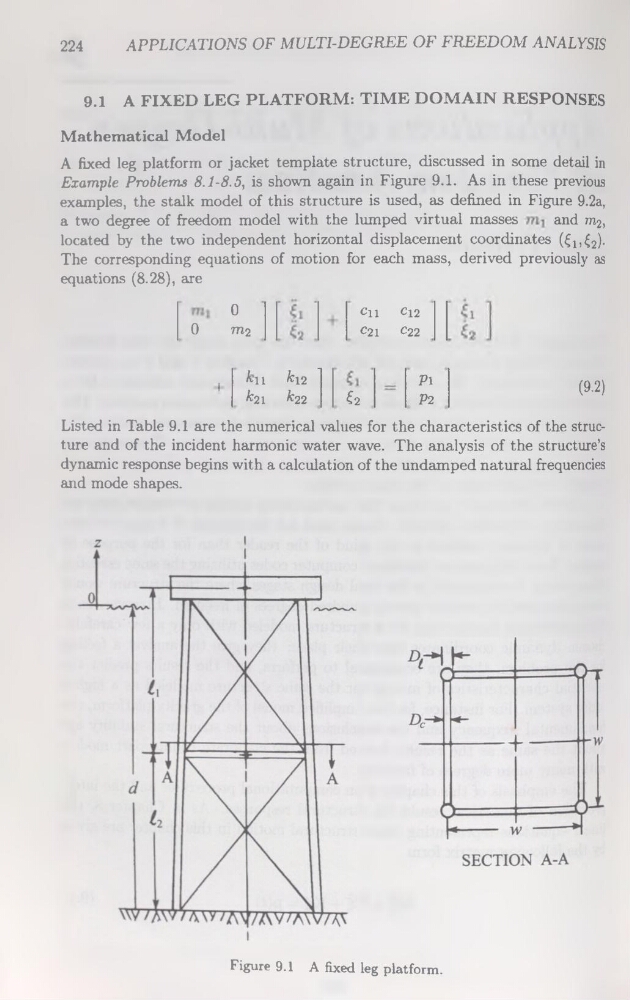
A fixed leg platform or jacket template structure, discussed in some detail in
Example Problems 8.1-8.5, is shown again in Figure 9.1. As in these préviens
examples, the stalk model of this structure is used, as defined in Figure 9.2a,
a two degree of freedom model with the lumped virtual masses
and m-z,
located by the two independent horizontal displacement coordinates (€ii€2)The corresponding équations of motion for each mass, derived previously as
équations (8.28), are
0
0
TTl2
C12
C22
Cil
C21
/lu
^21
^12 1
A?22
Pi
P2
4
Listed in Table 9.1 are the numerical values for the characteristics of the structure and of the incident harmonie water wave. The analysis of the structurel
dynamic response begins with a calculation of the undamped natural frequencies
and mode shapes.
(9.2)
Figure 9.1 A fixed leg platform.
G