

22
I.
Introduction
3><
χ
>
q(x)
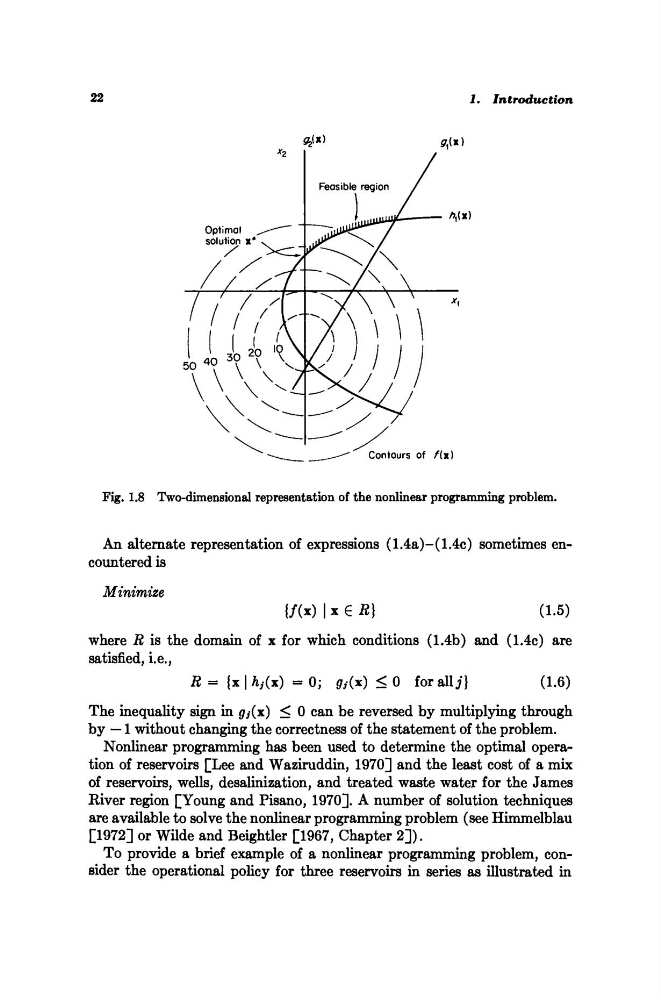
Fig. 1.8 Two-dimensional representation of the nonlinear programming problem.
An alternate representation of expressions (1.4a)-(1.4c) sometimes encountered is
Minimize
{/(*) I x 6 R}
(1.5)
where β is the domain of χ for which conditions (1.4b) and (1.4c) are
satisfied, i.e.,
R = {χ I h,(x) = 0; £/(x) < 0 for alii}
(1.6)
The inequality sign in gry(x) < 0 can be reversed by multiplying through
by — 1 without changing the correctness of the statement of the problem.
Nonlinear programming has been used to determine the optimal operation of reservoirs [Lee and Waziruddin, 1970] and the least cost of a mix
of reservoirs, wells, desalinization, and treated waste water for the James
River region [Young and Pisano, 1970]. A number of solution techniques
are available to solve the nonlinear programming problem (see Himmelblau
[1972] or Wilde and Beightler [1967, Chapter 2]).
To provide a brief example of a nonlinear programming problem, consider the operational policy for three reservoirs in series as illustrated in